Hi, my name is

Julian aka.WangJiaXing

I believe that engineer solutions should be solved through precision design.

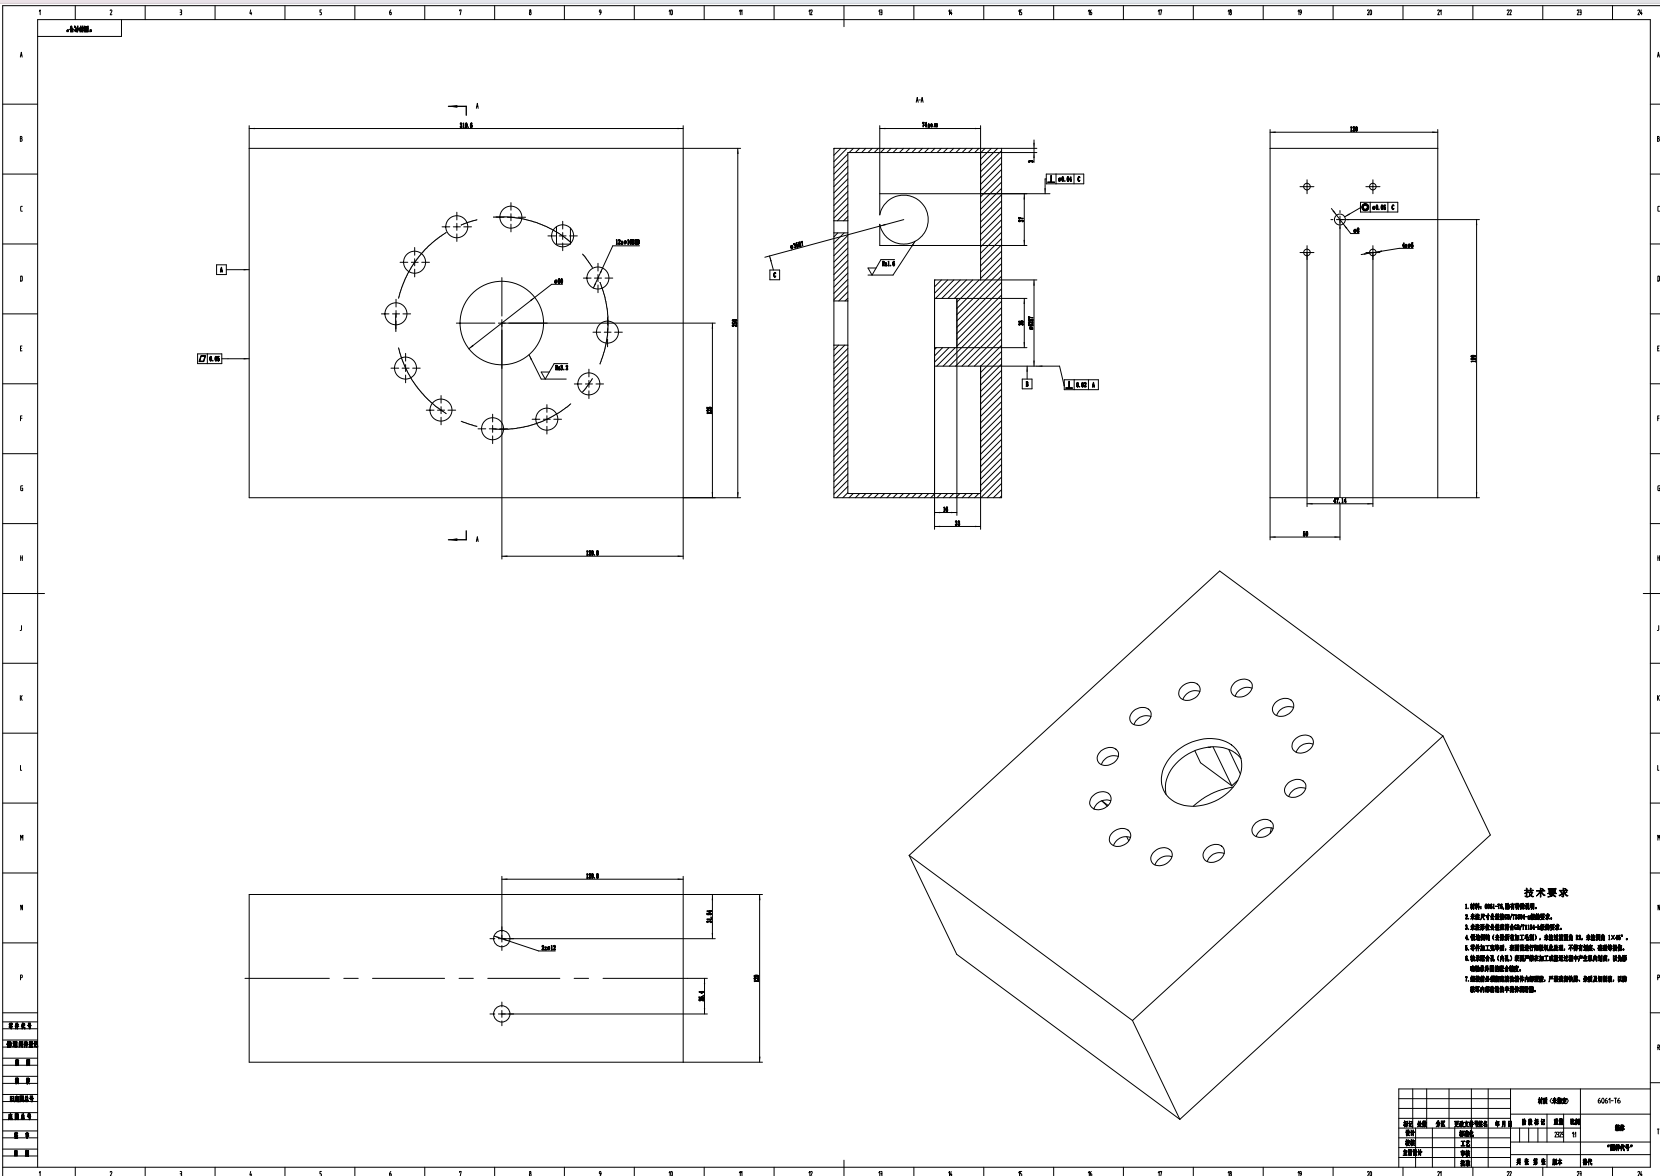
I am a Mechanical Design & Engineer college student, structural analysis, and complex automated machinery. I can transform concepts into manufacturable, high-performance physical systems.

01.About Me

Hello! My name is Julian and I enjoy designing robust mechanical systems that solve real-world problems. My interest in mechanical engineering started back in high school when I first learned to use a 3D printer—only to realize the delicate balance between structural integrity and precise kinematics.

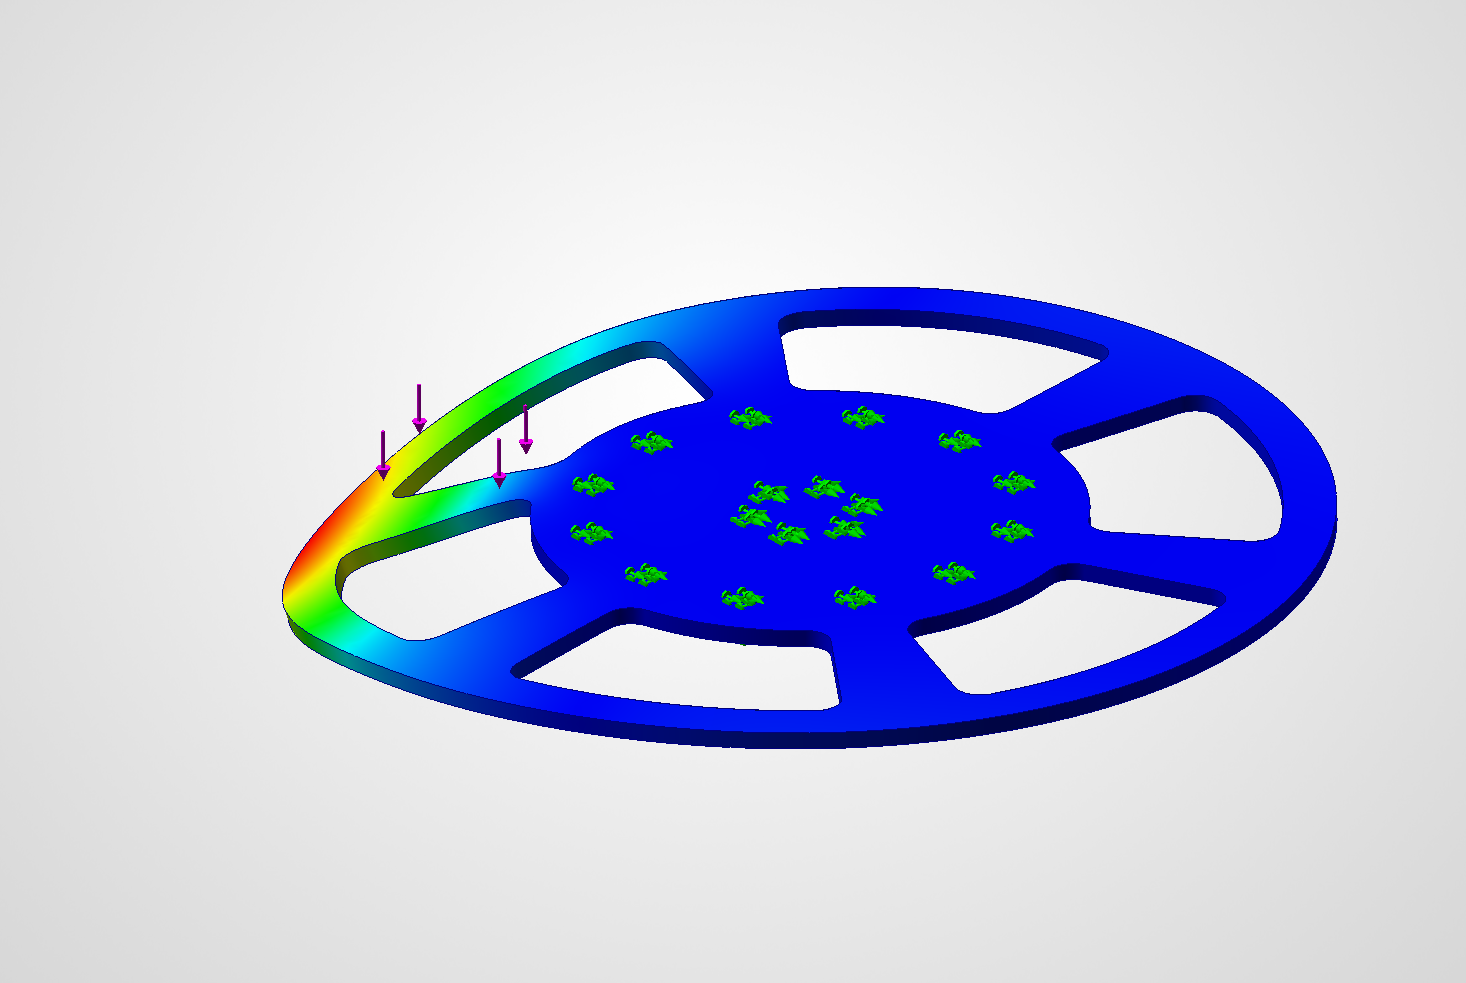
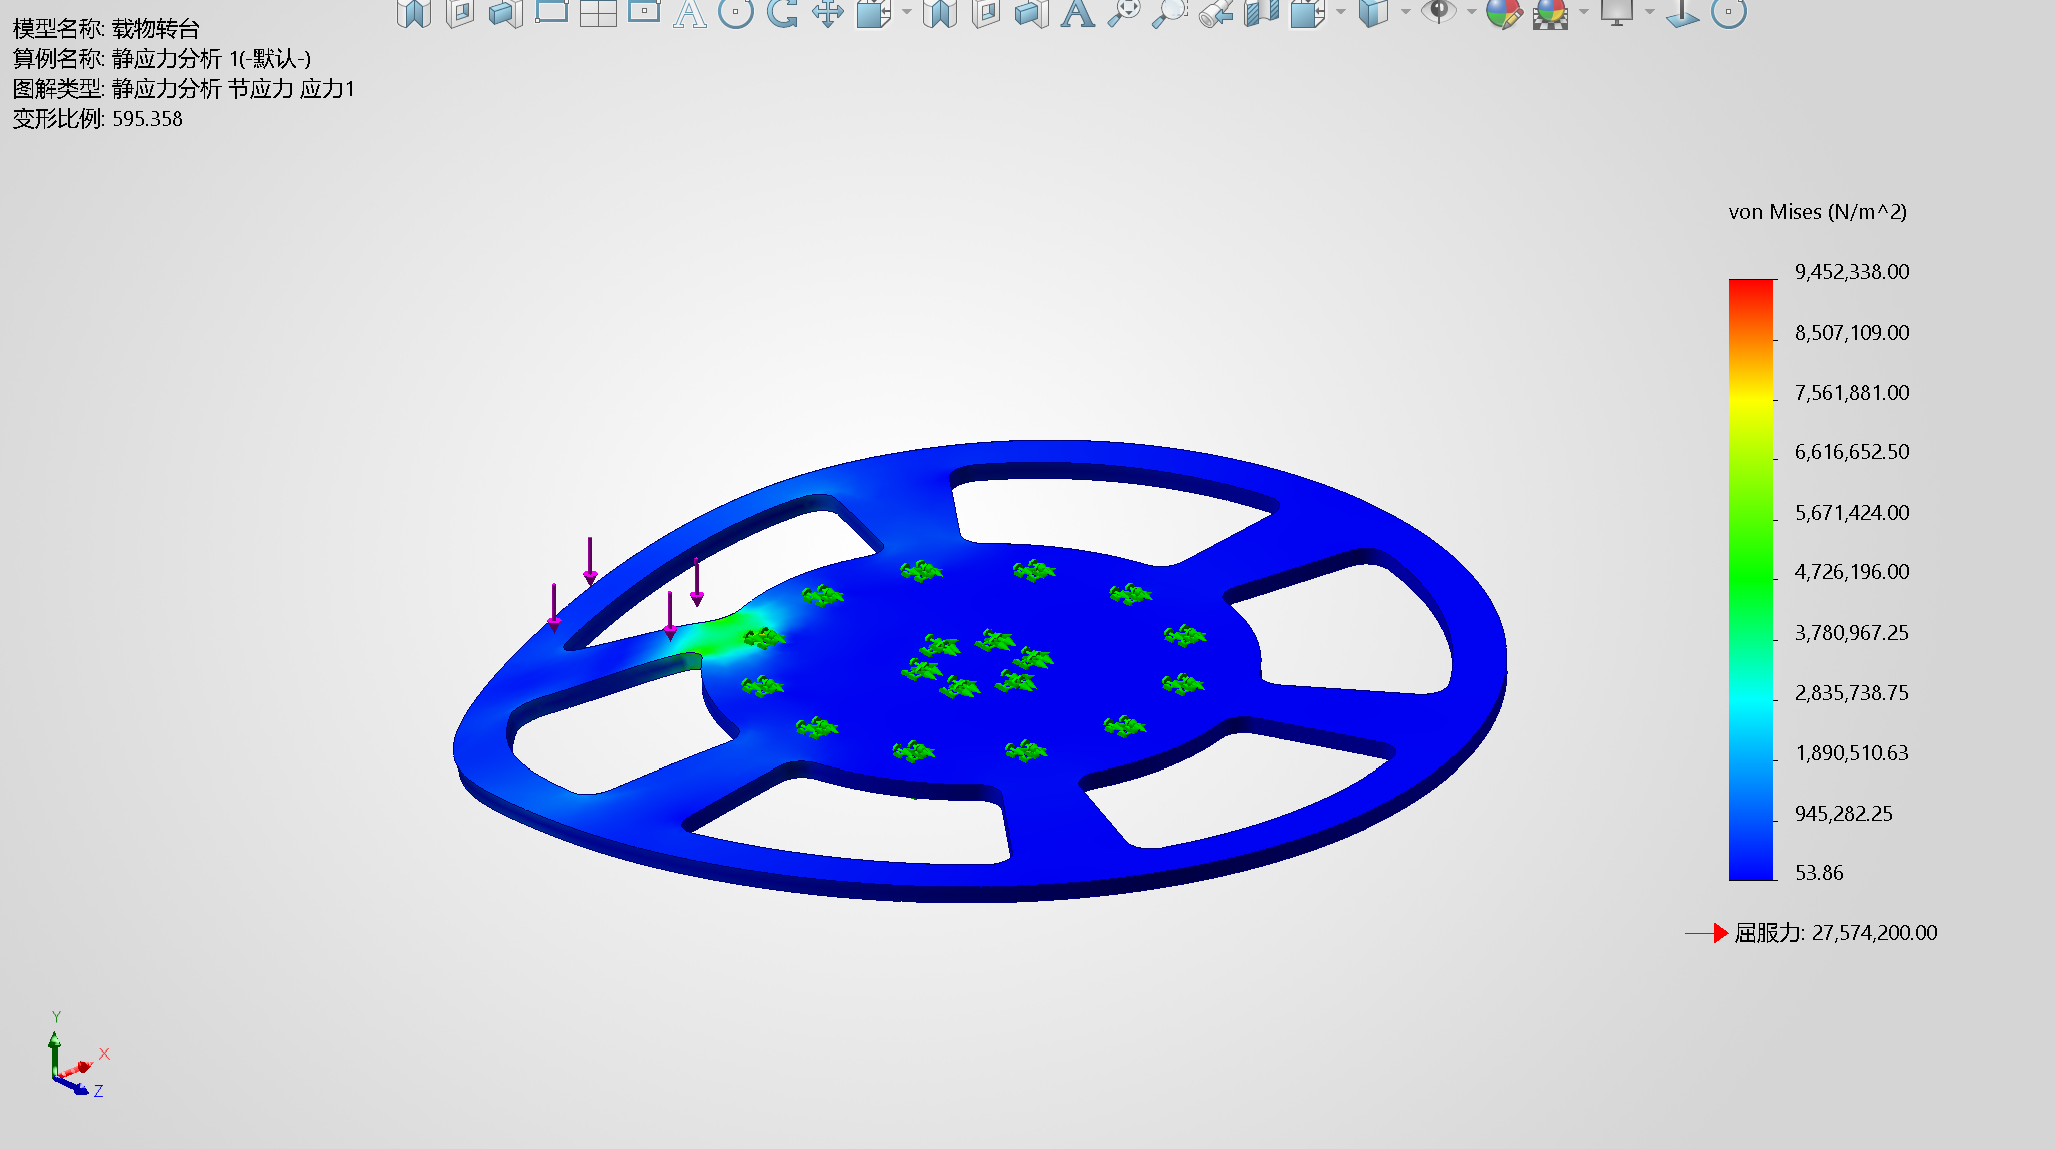
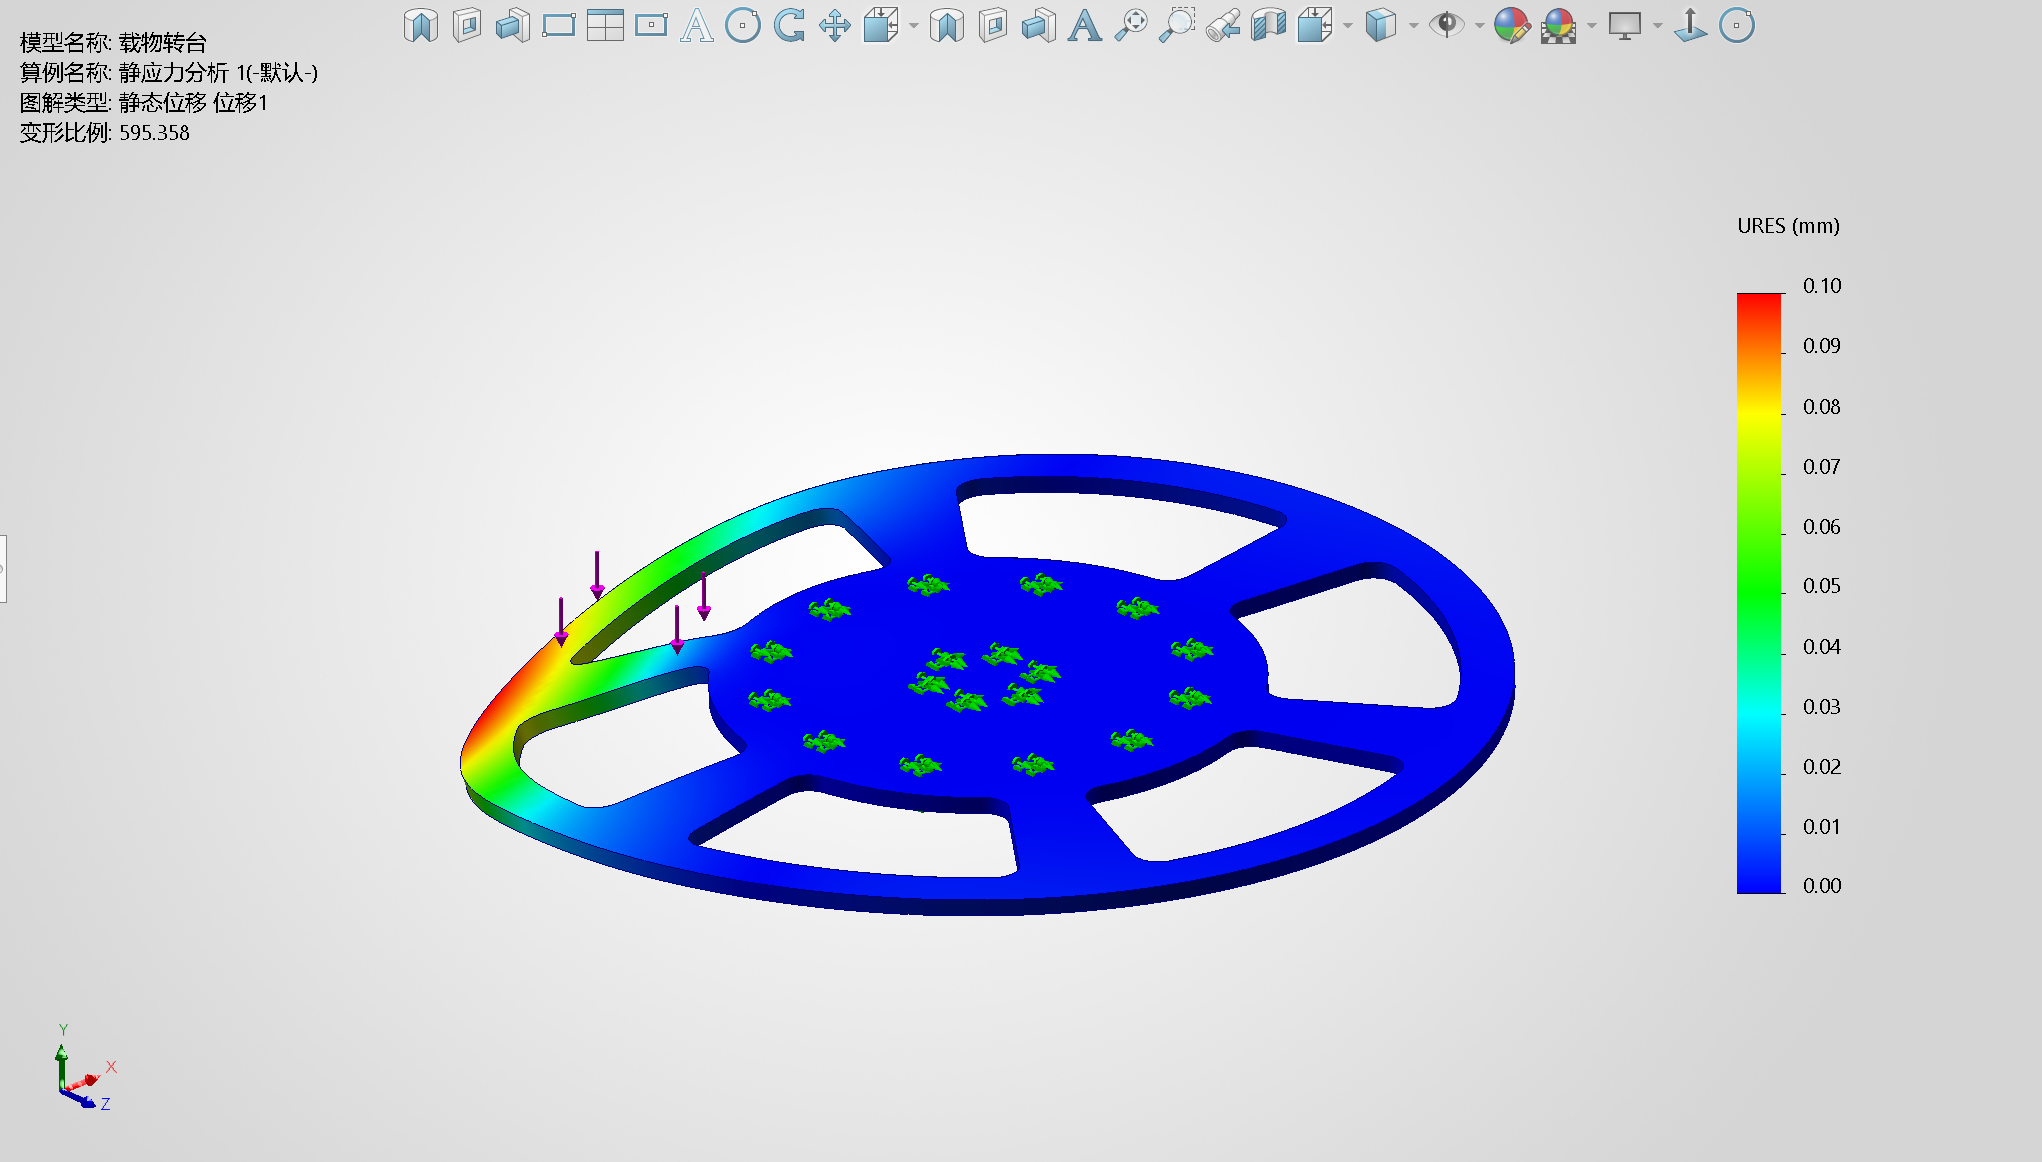
Fast forward to today, I have had the privilege of designing automation equipment for agriculture, prototyping robotic systems, and conducting complex structural analyses. My main focus these days is building scalable, highly-efficient machinery using advanced CAD tools and FEA validation.

When I'm not designing in SolidWorks or tweaking microcontrollers, you can find me reading some books or playing computer game with my classmate.
John Doe

02.Core Competencies

SolidWorks 2026

3D CAD & Assembly

FEA Simulation

Stress & Thermal

MATLAB

Data & Kinematics

Microcontrollers

Keil / C Programming

Structural Design

GD&T & Tolerance

03.Featured Projects

Sorting Machine

Featured Case Study

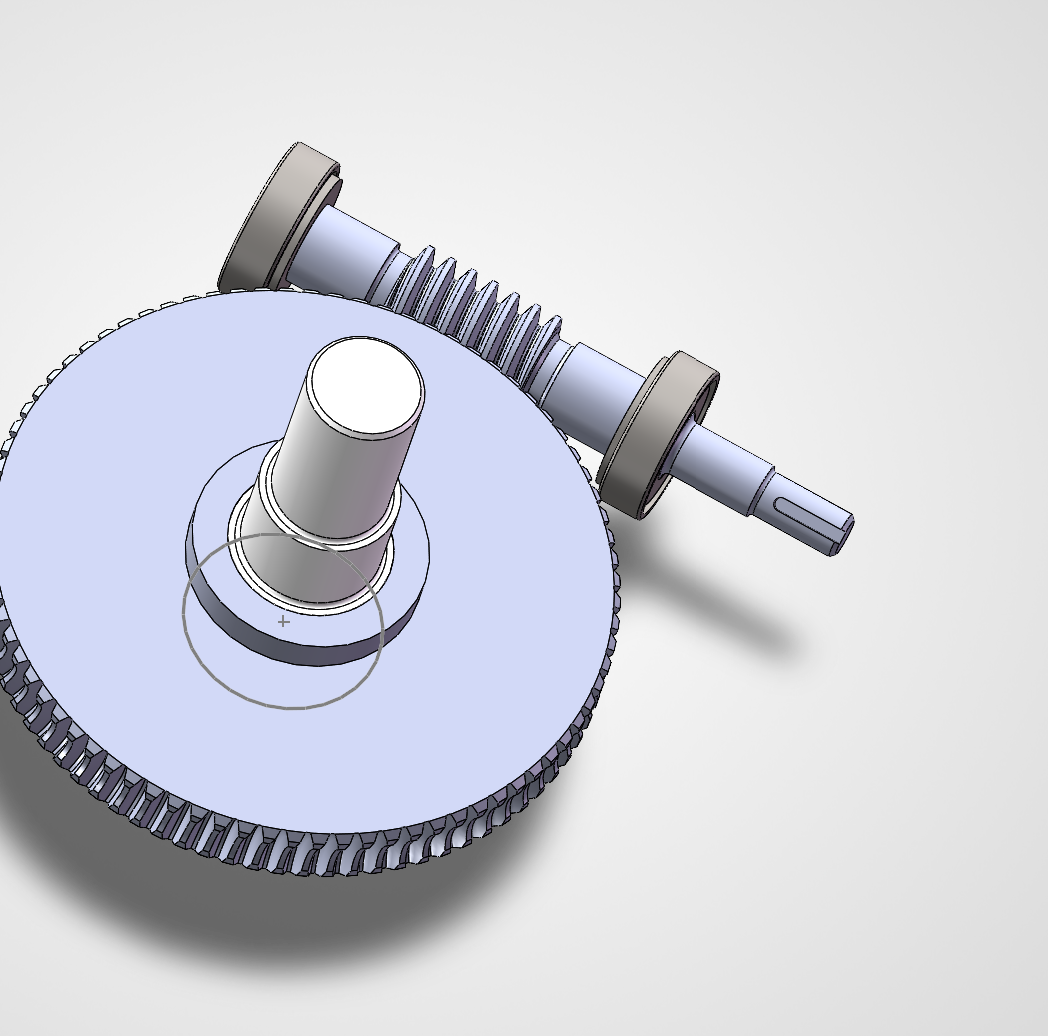
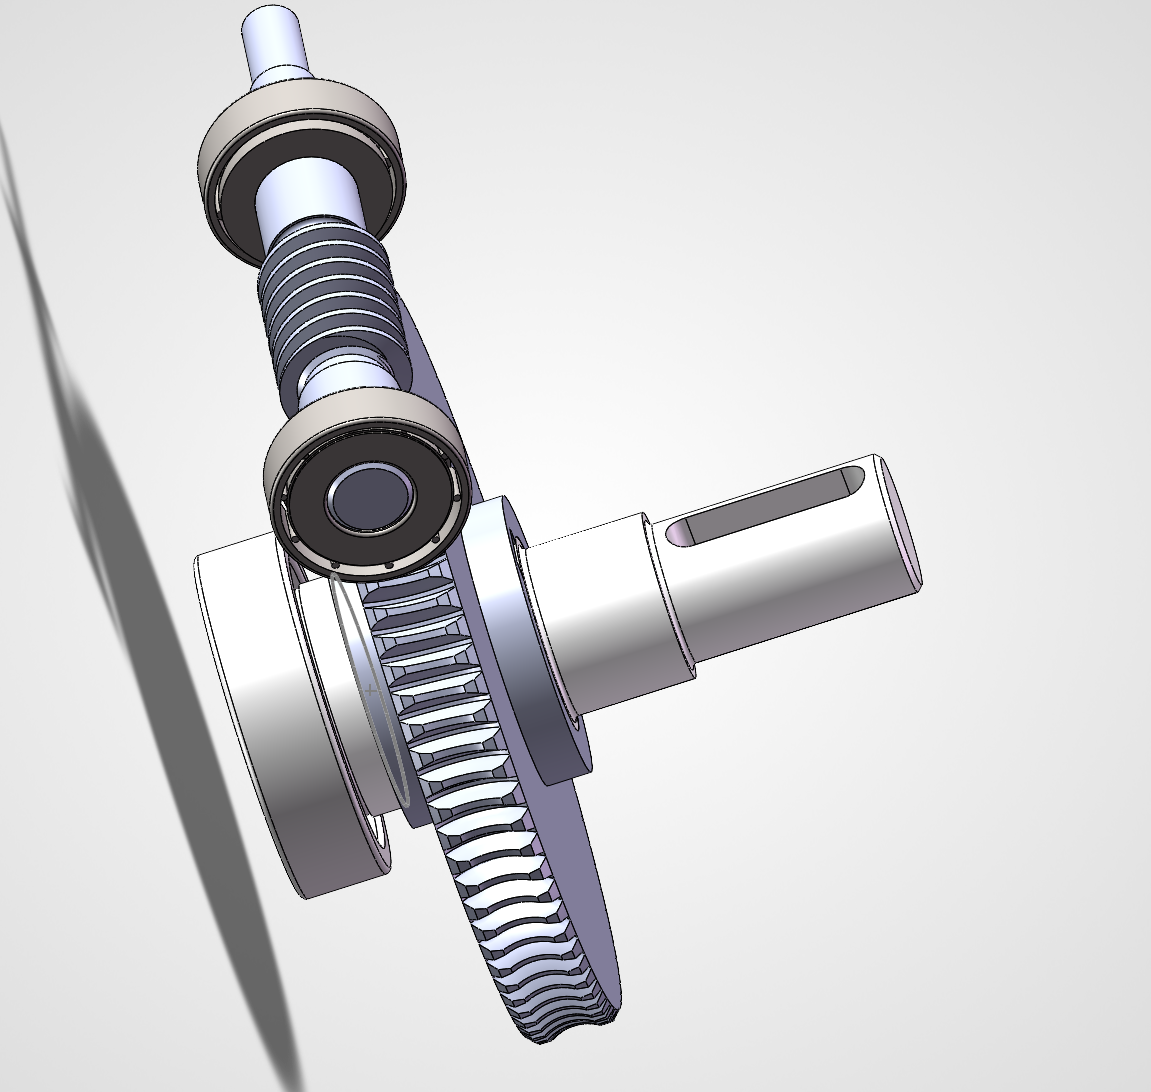
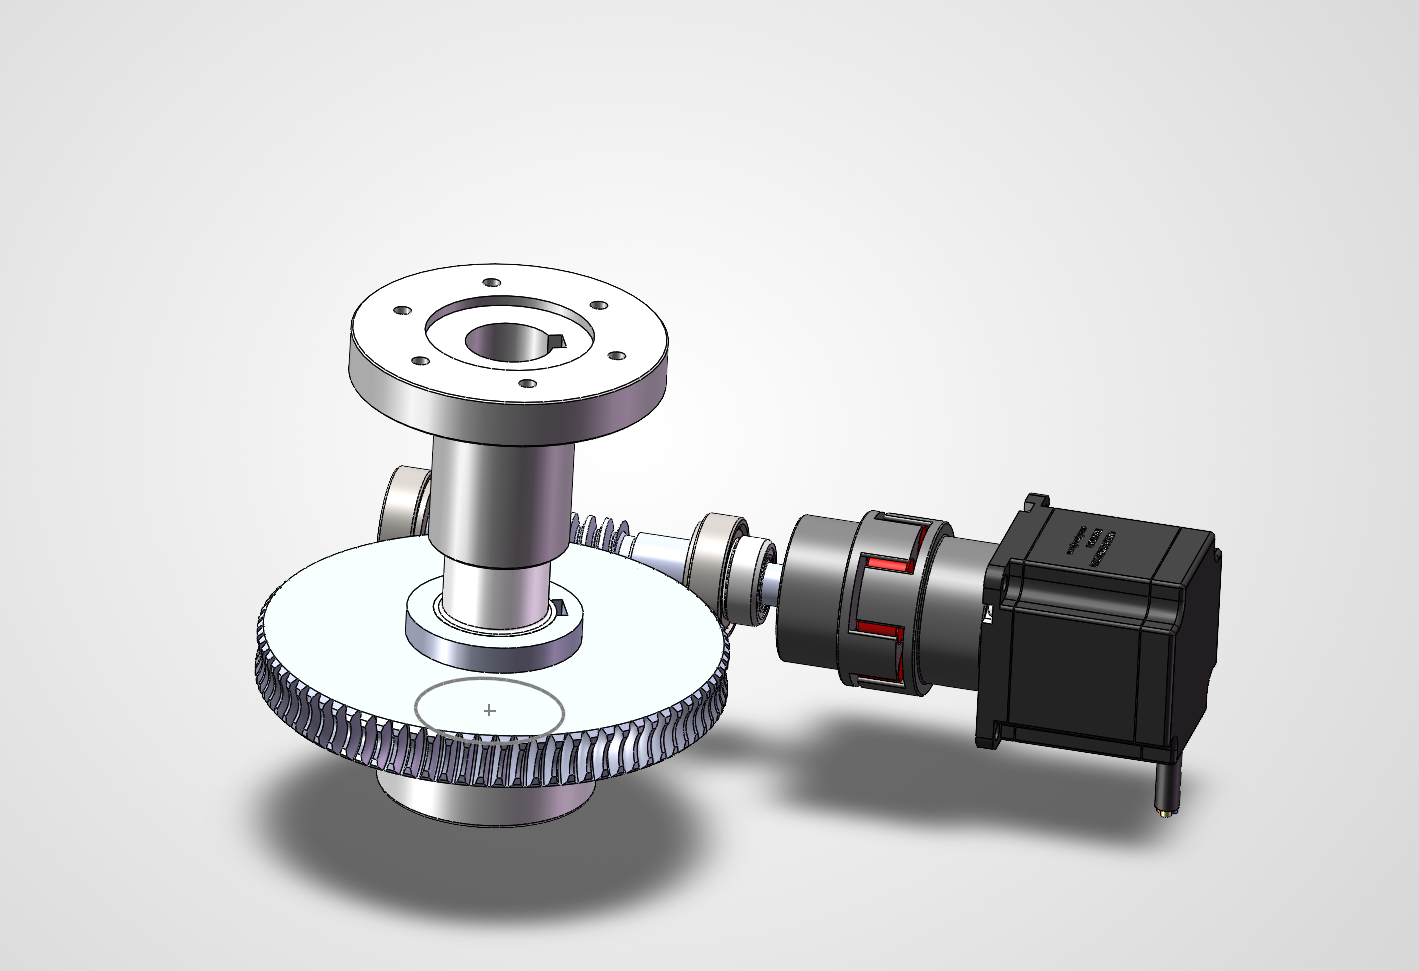
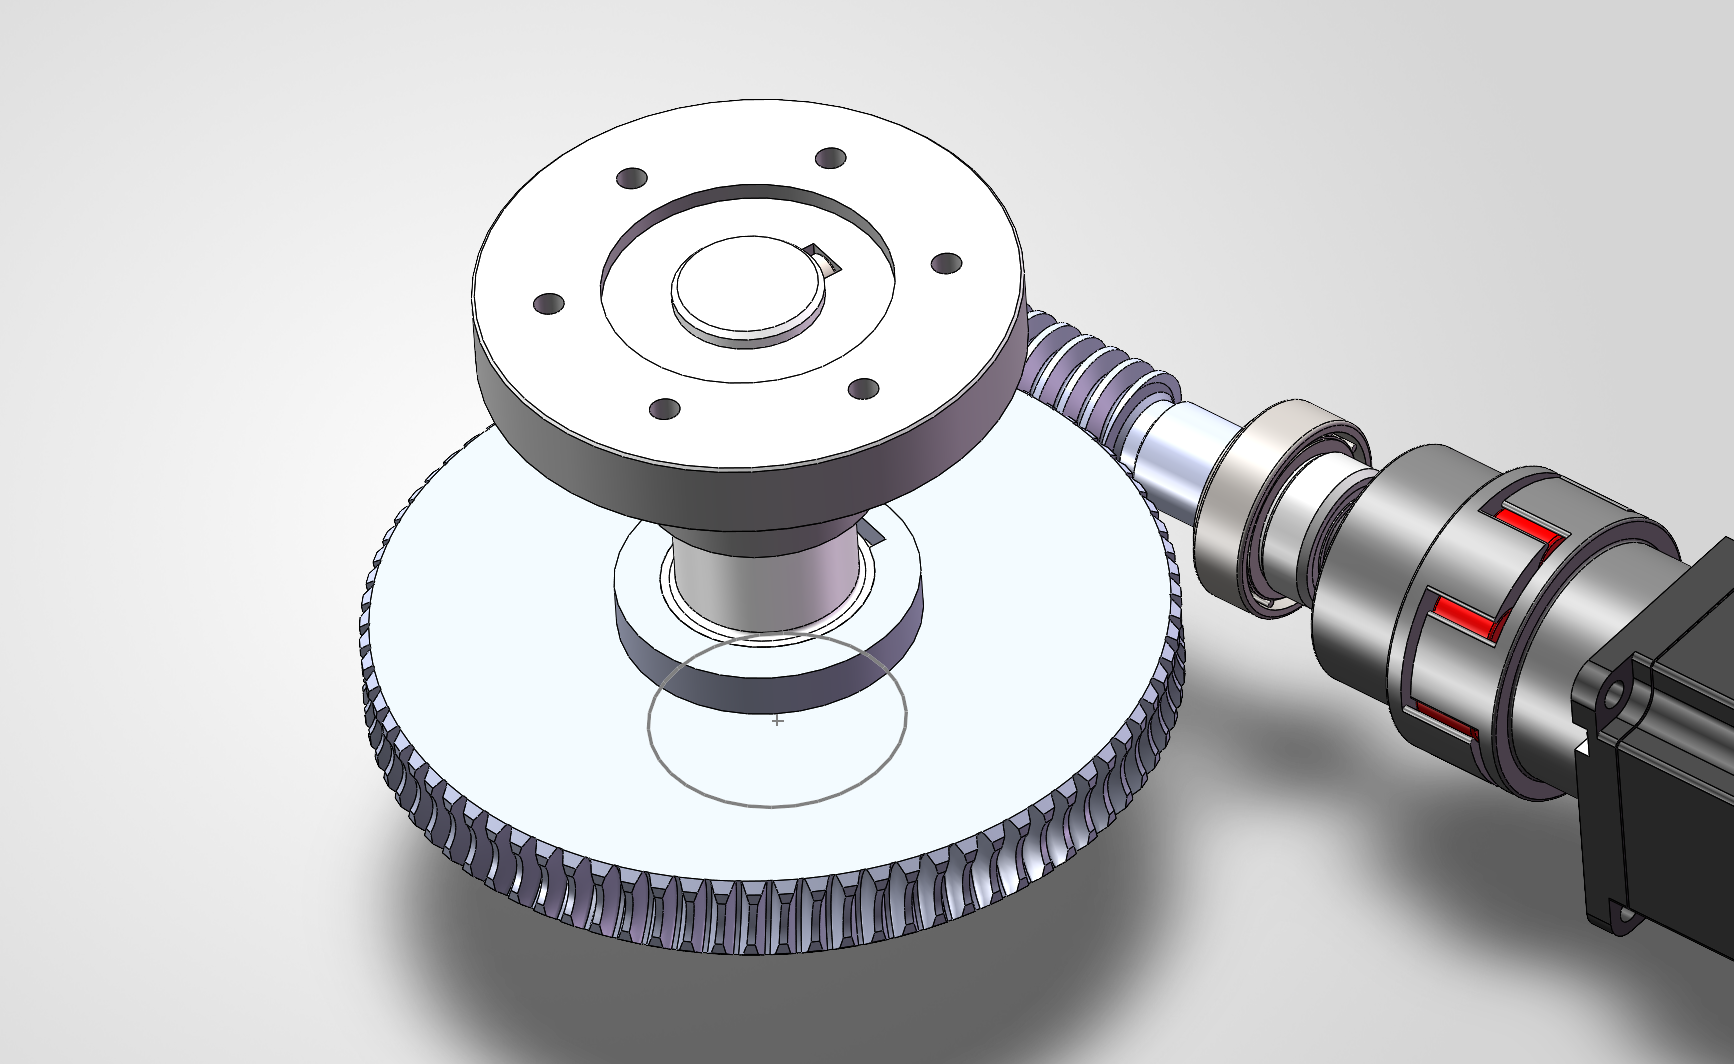
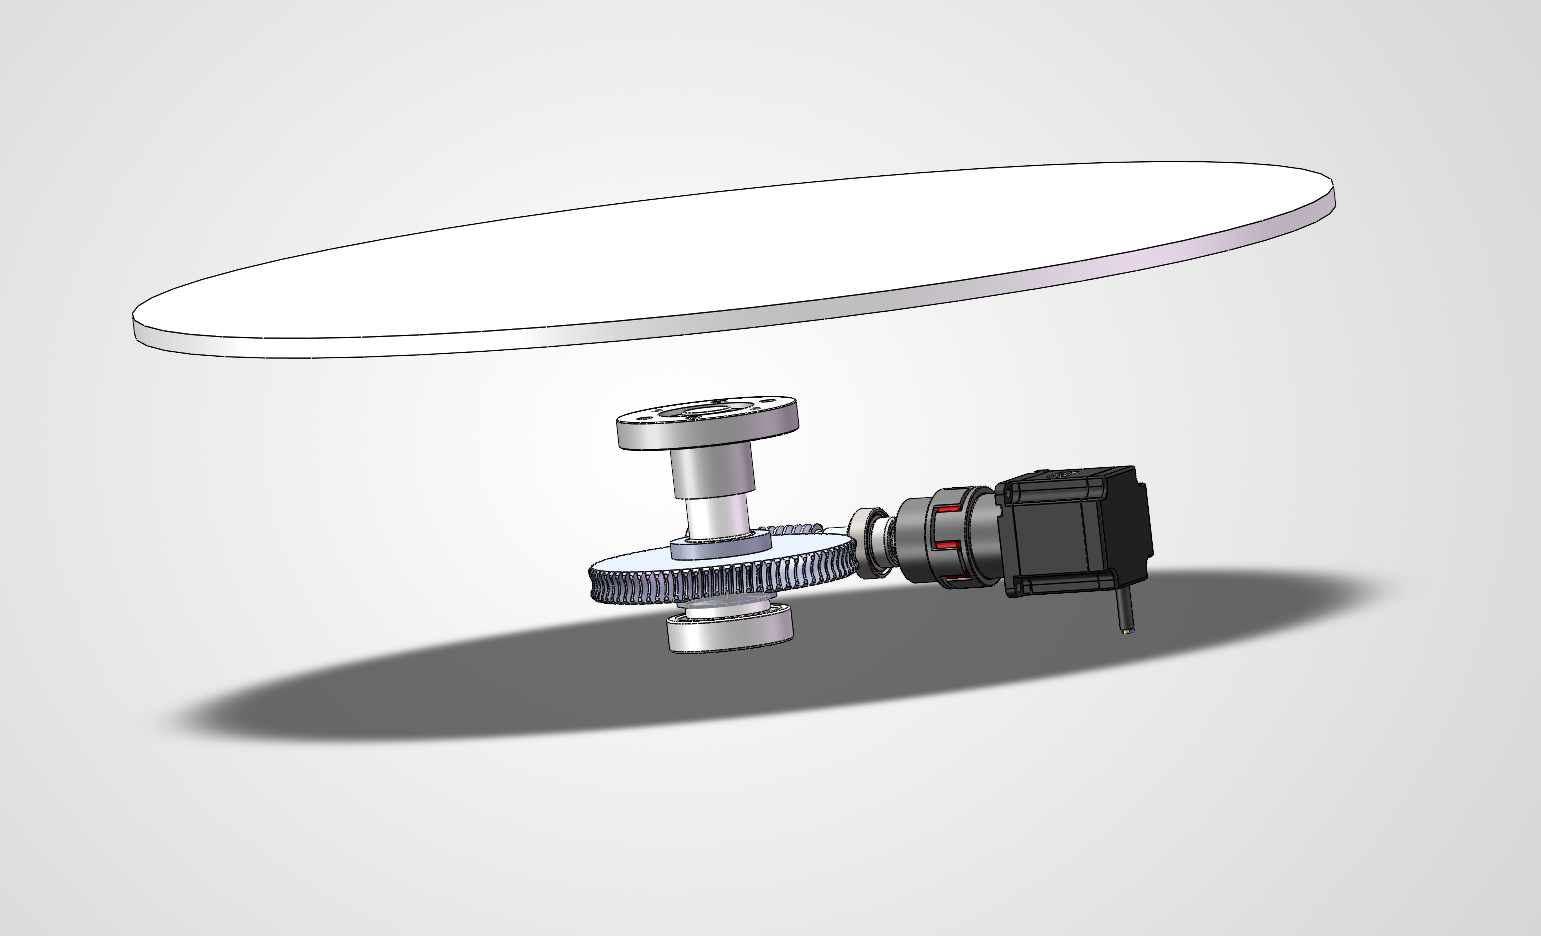
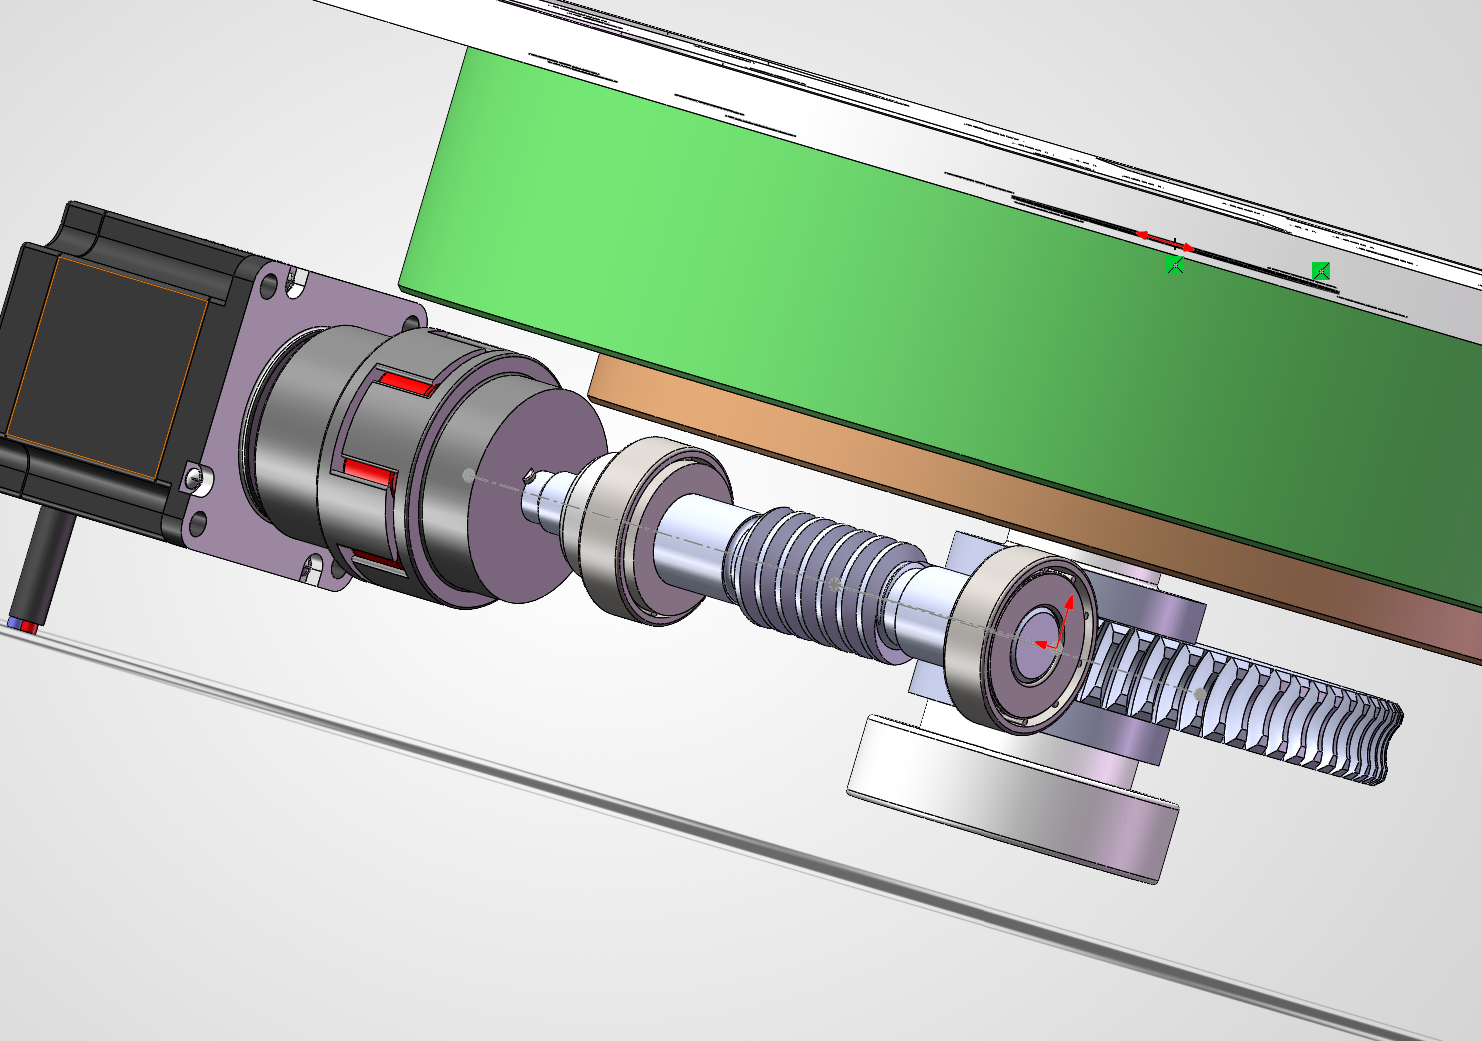
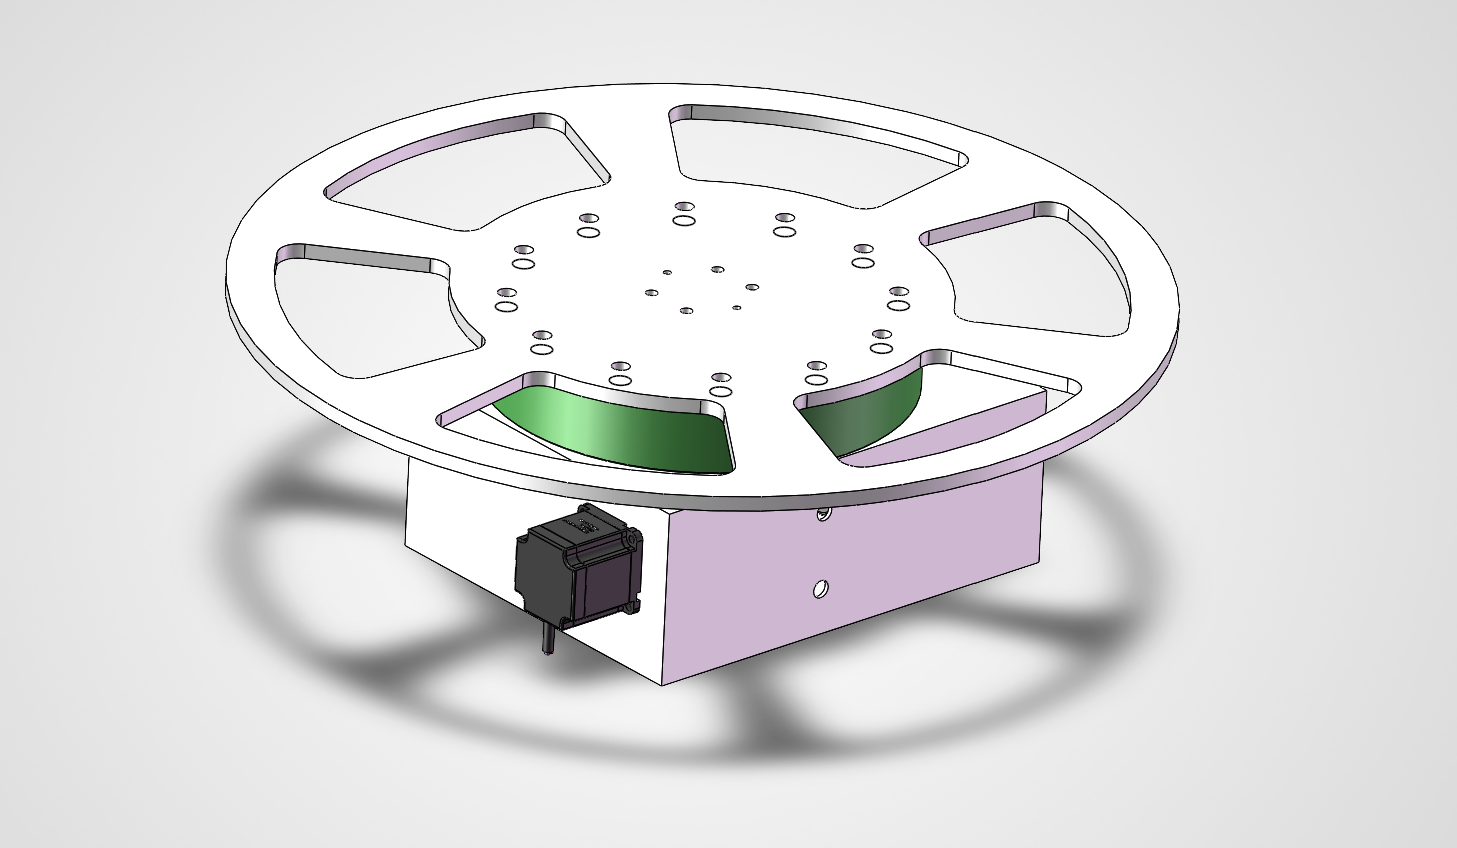
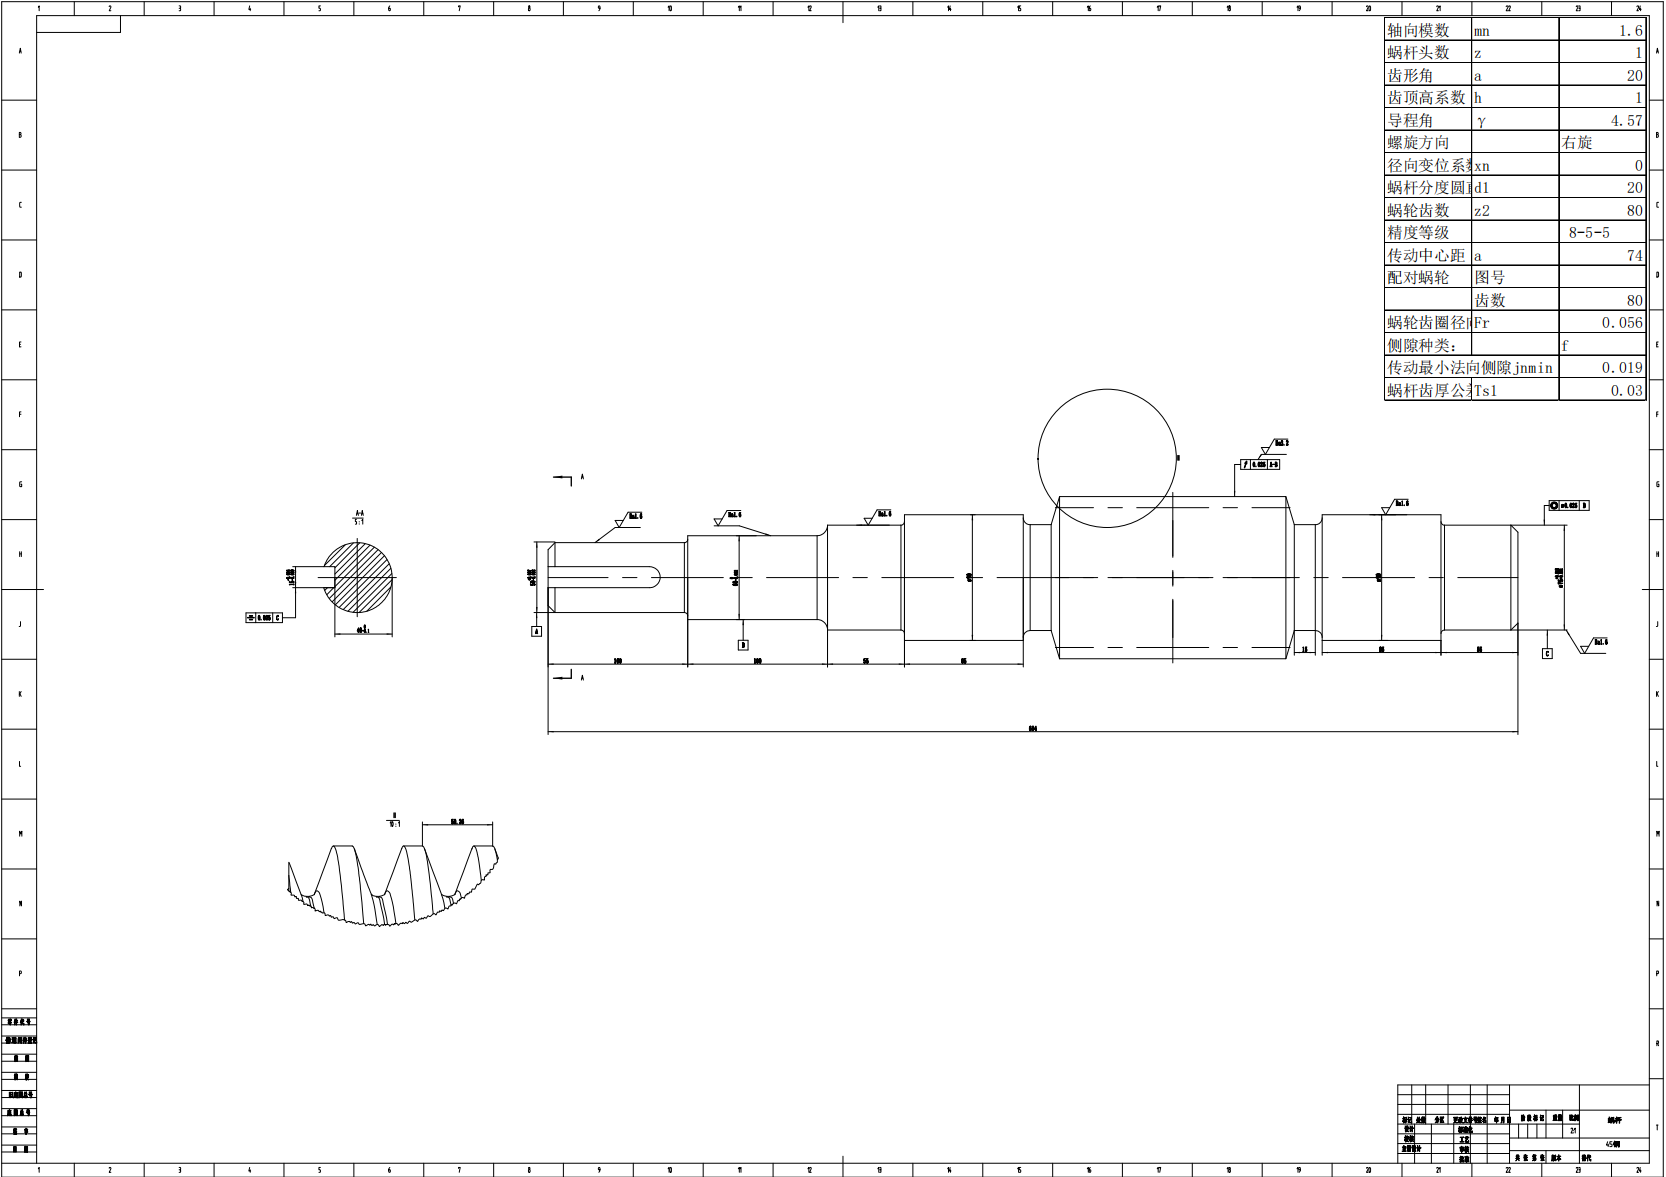
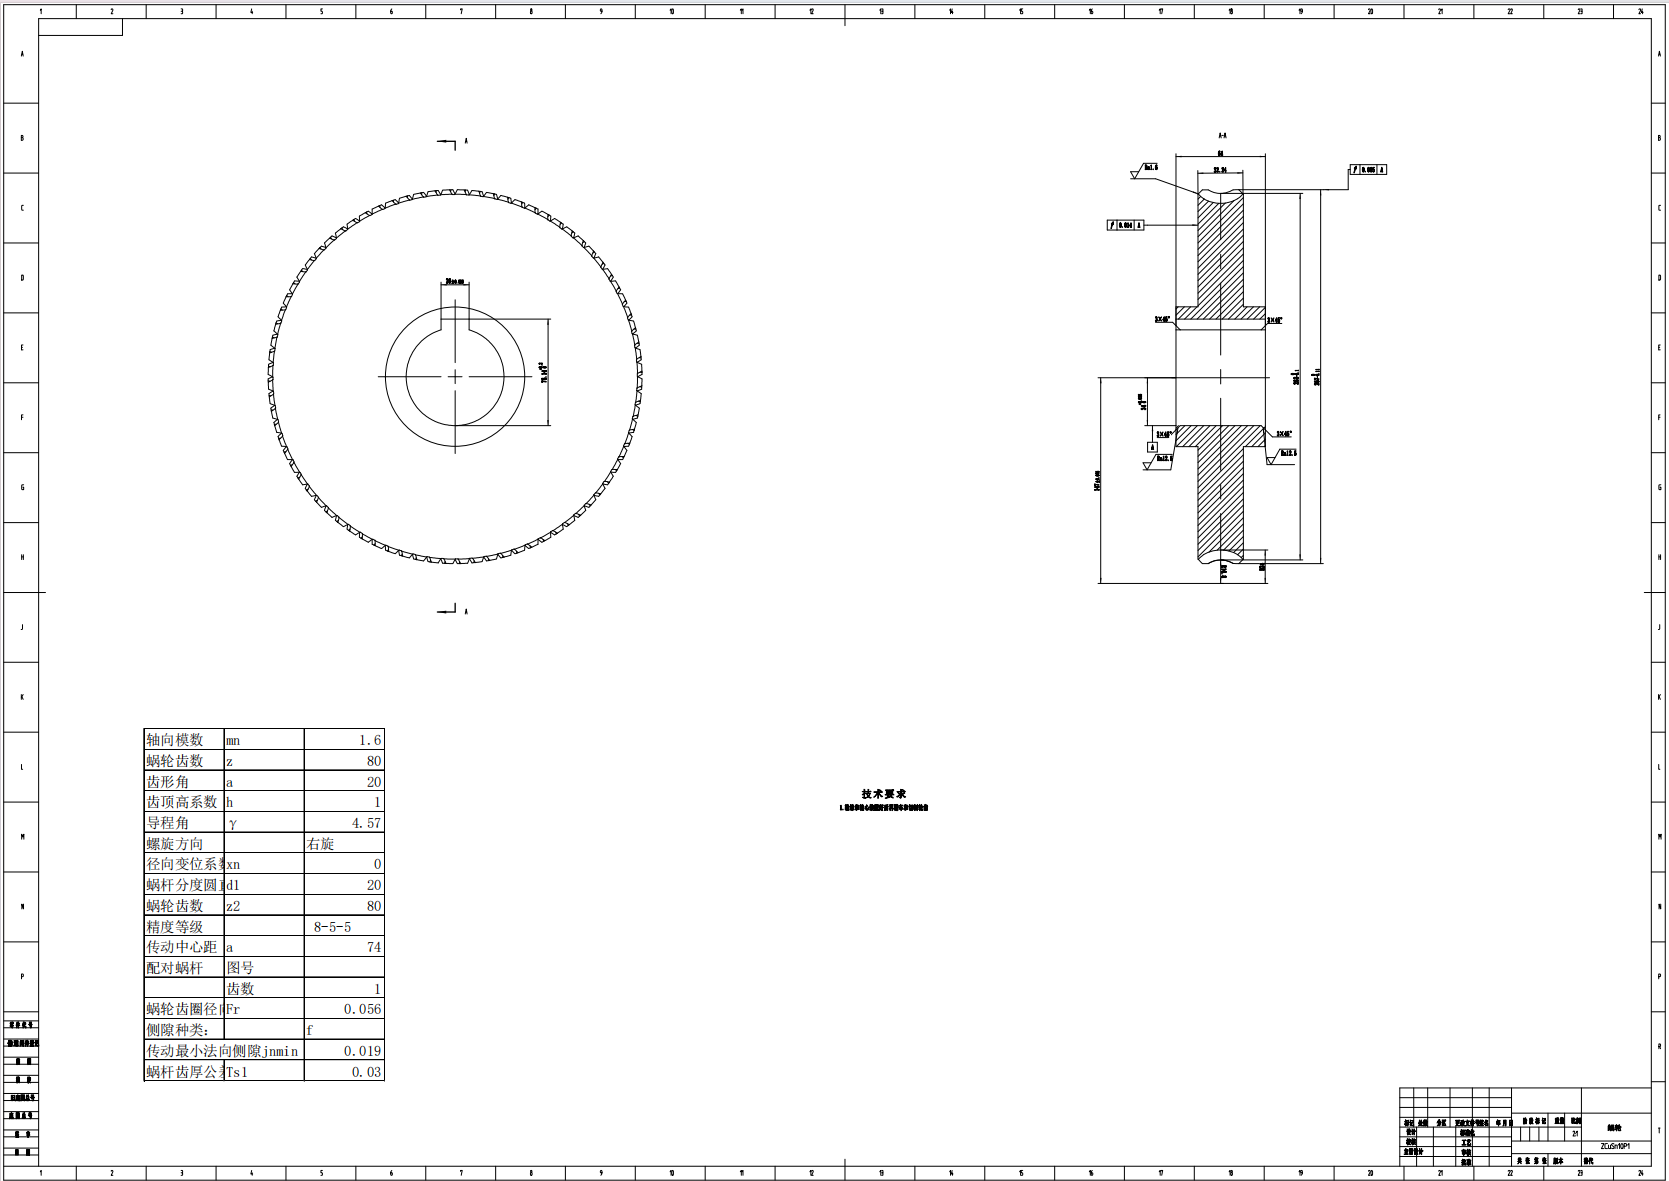
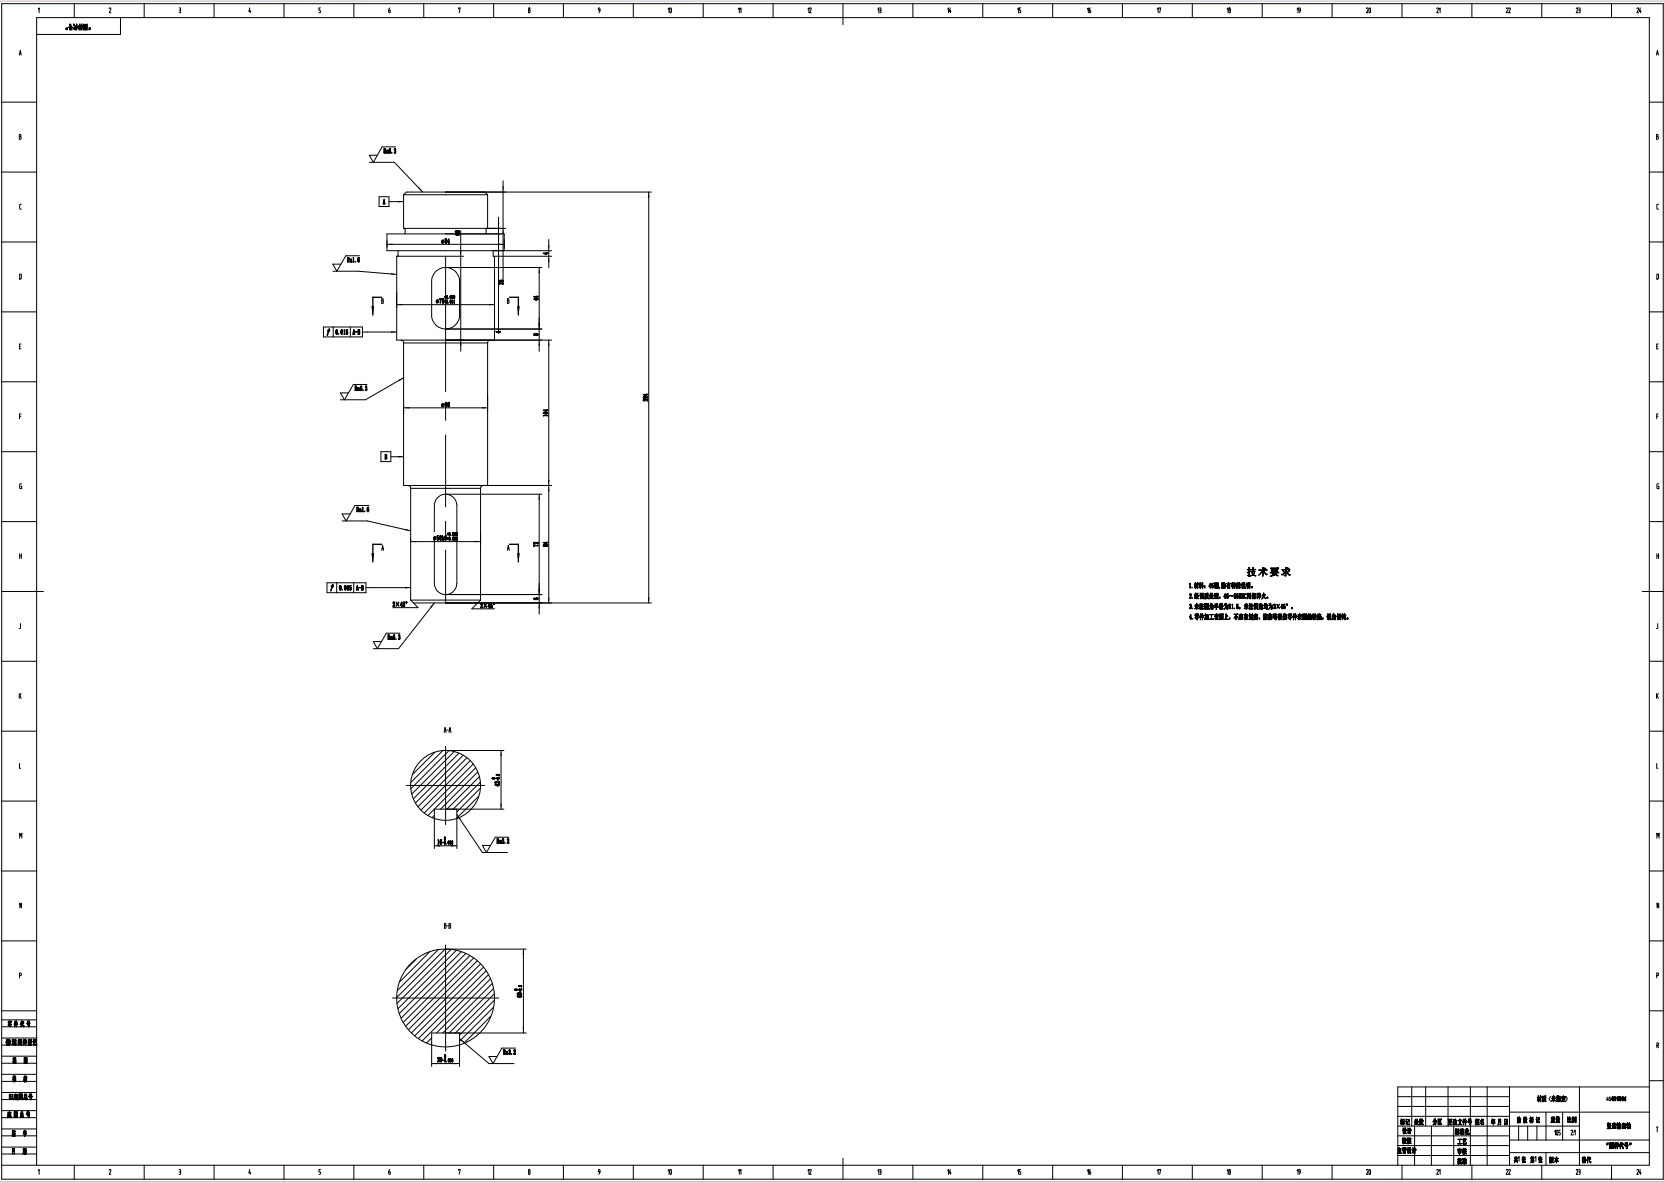
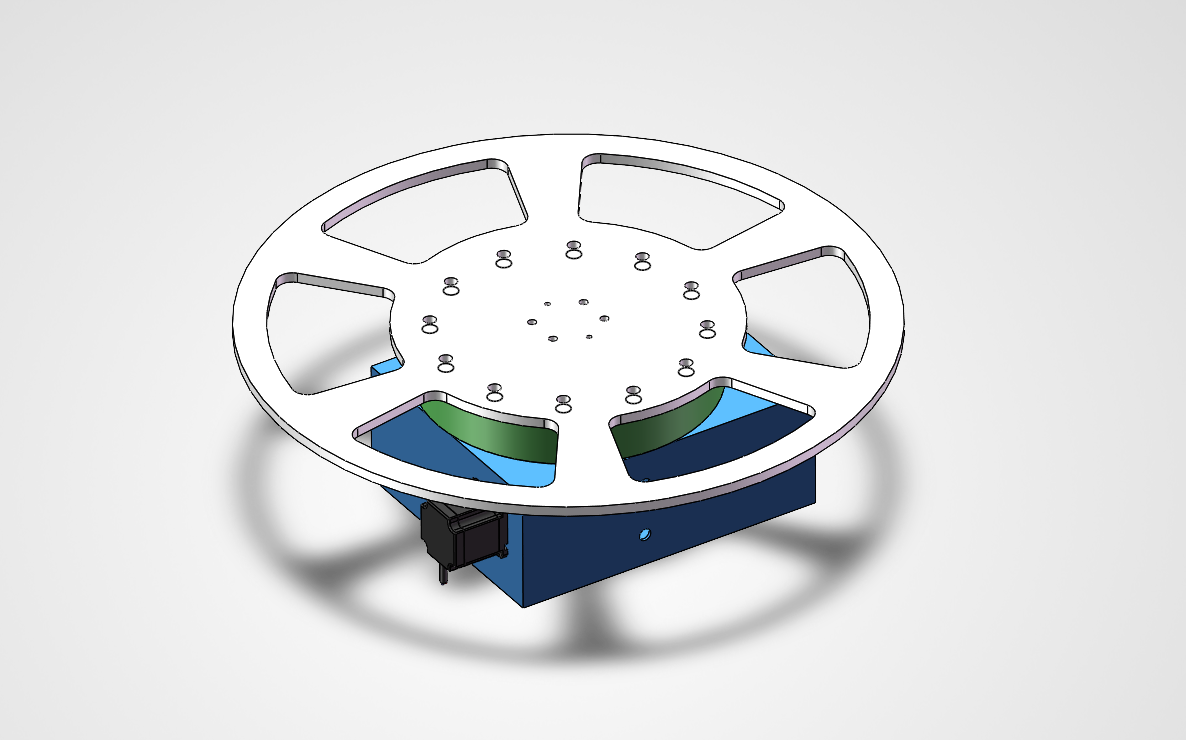
Fruit & Veg Sorting Machine Worm Drive

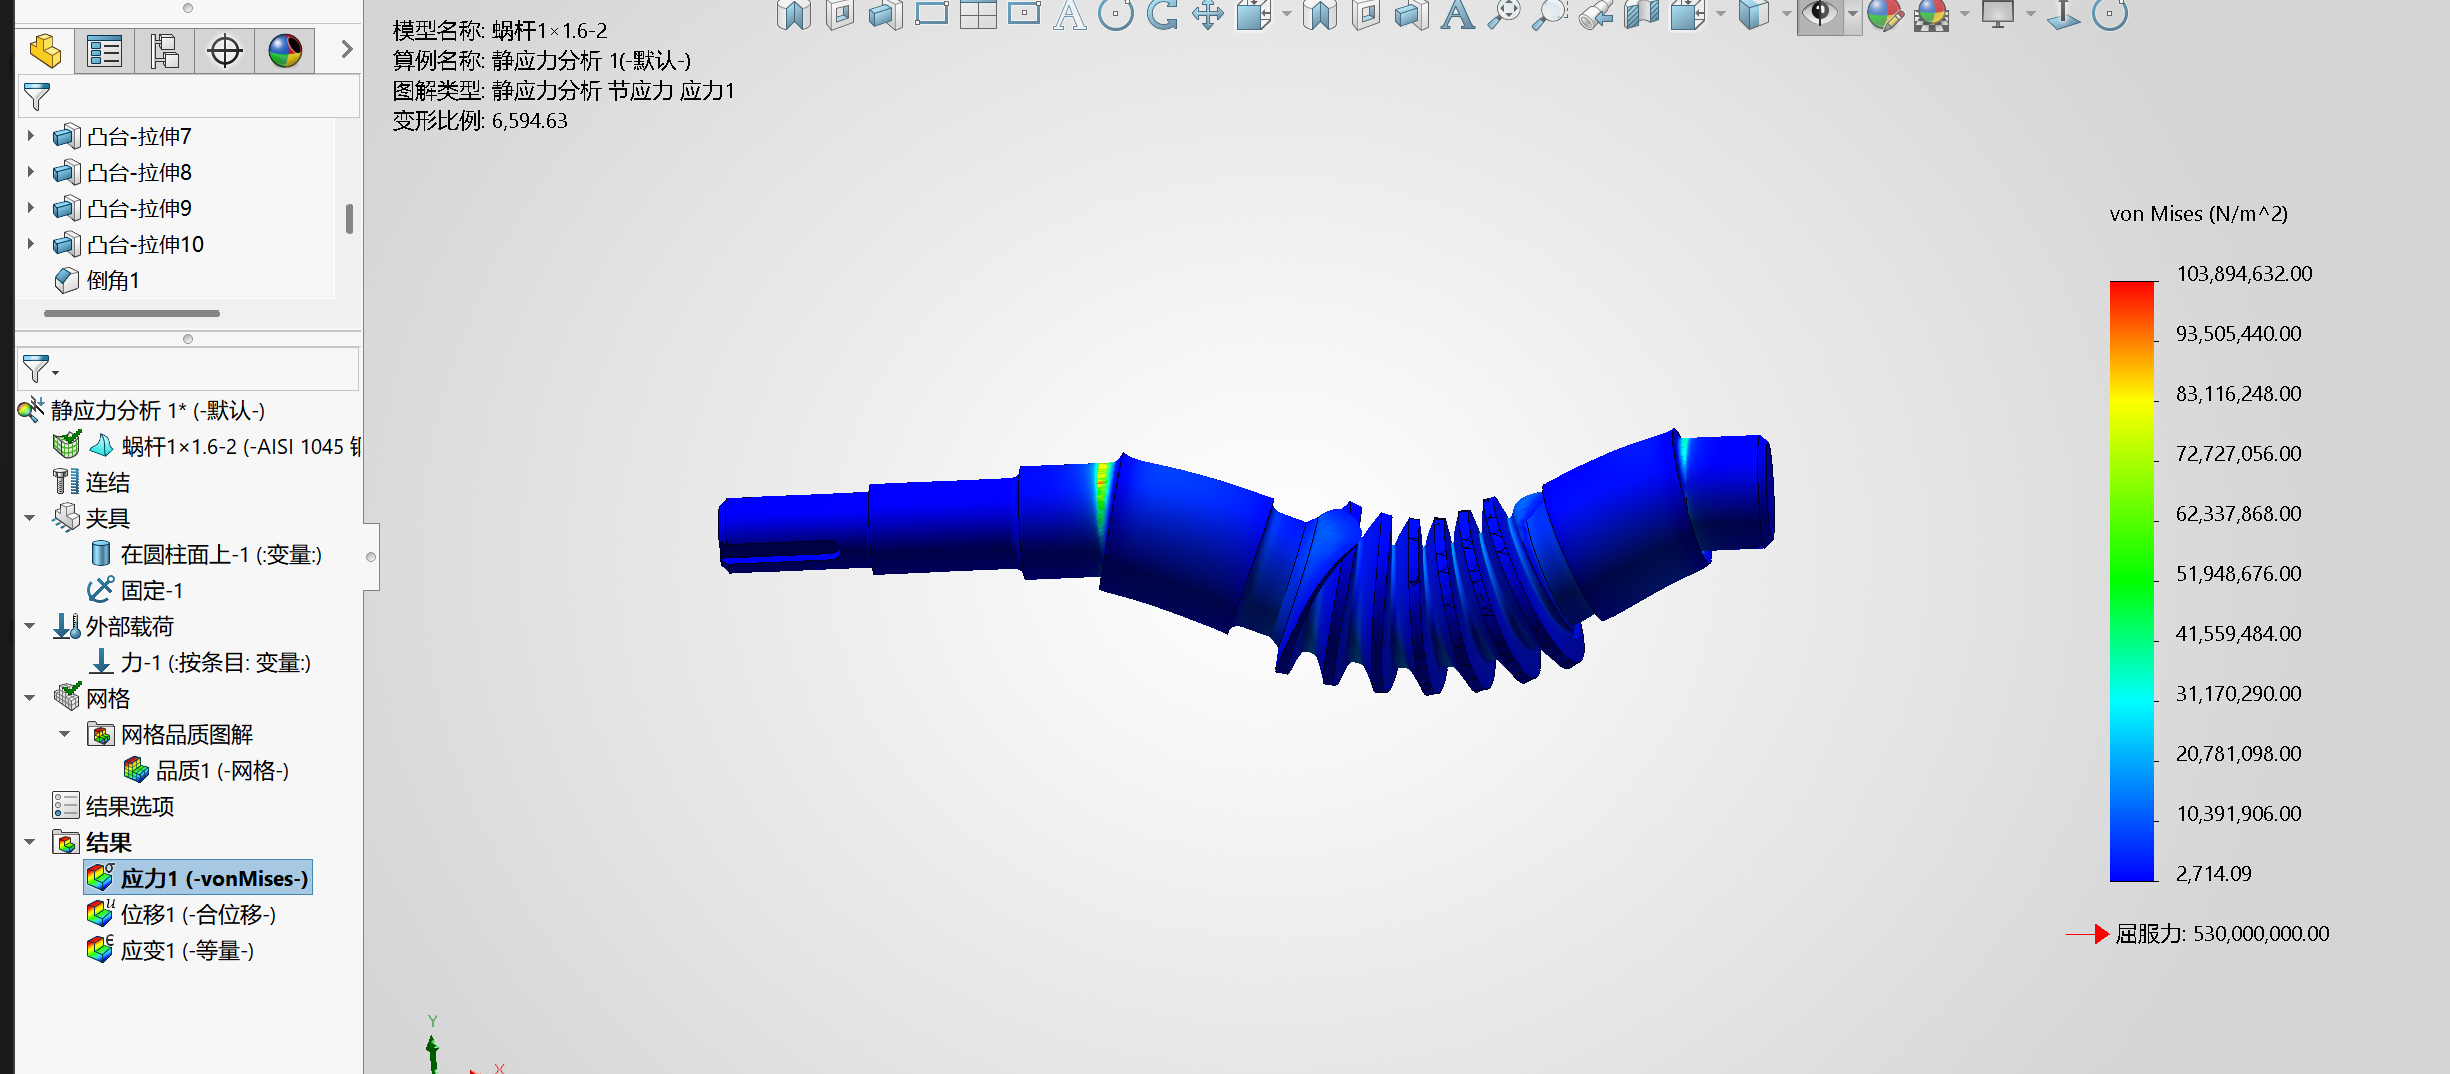
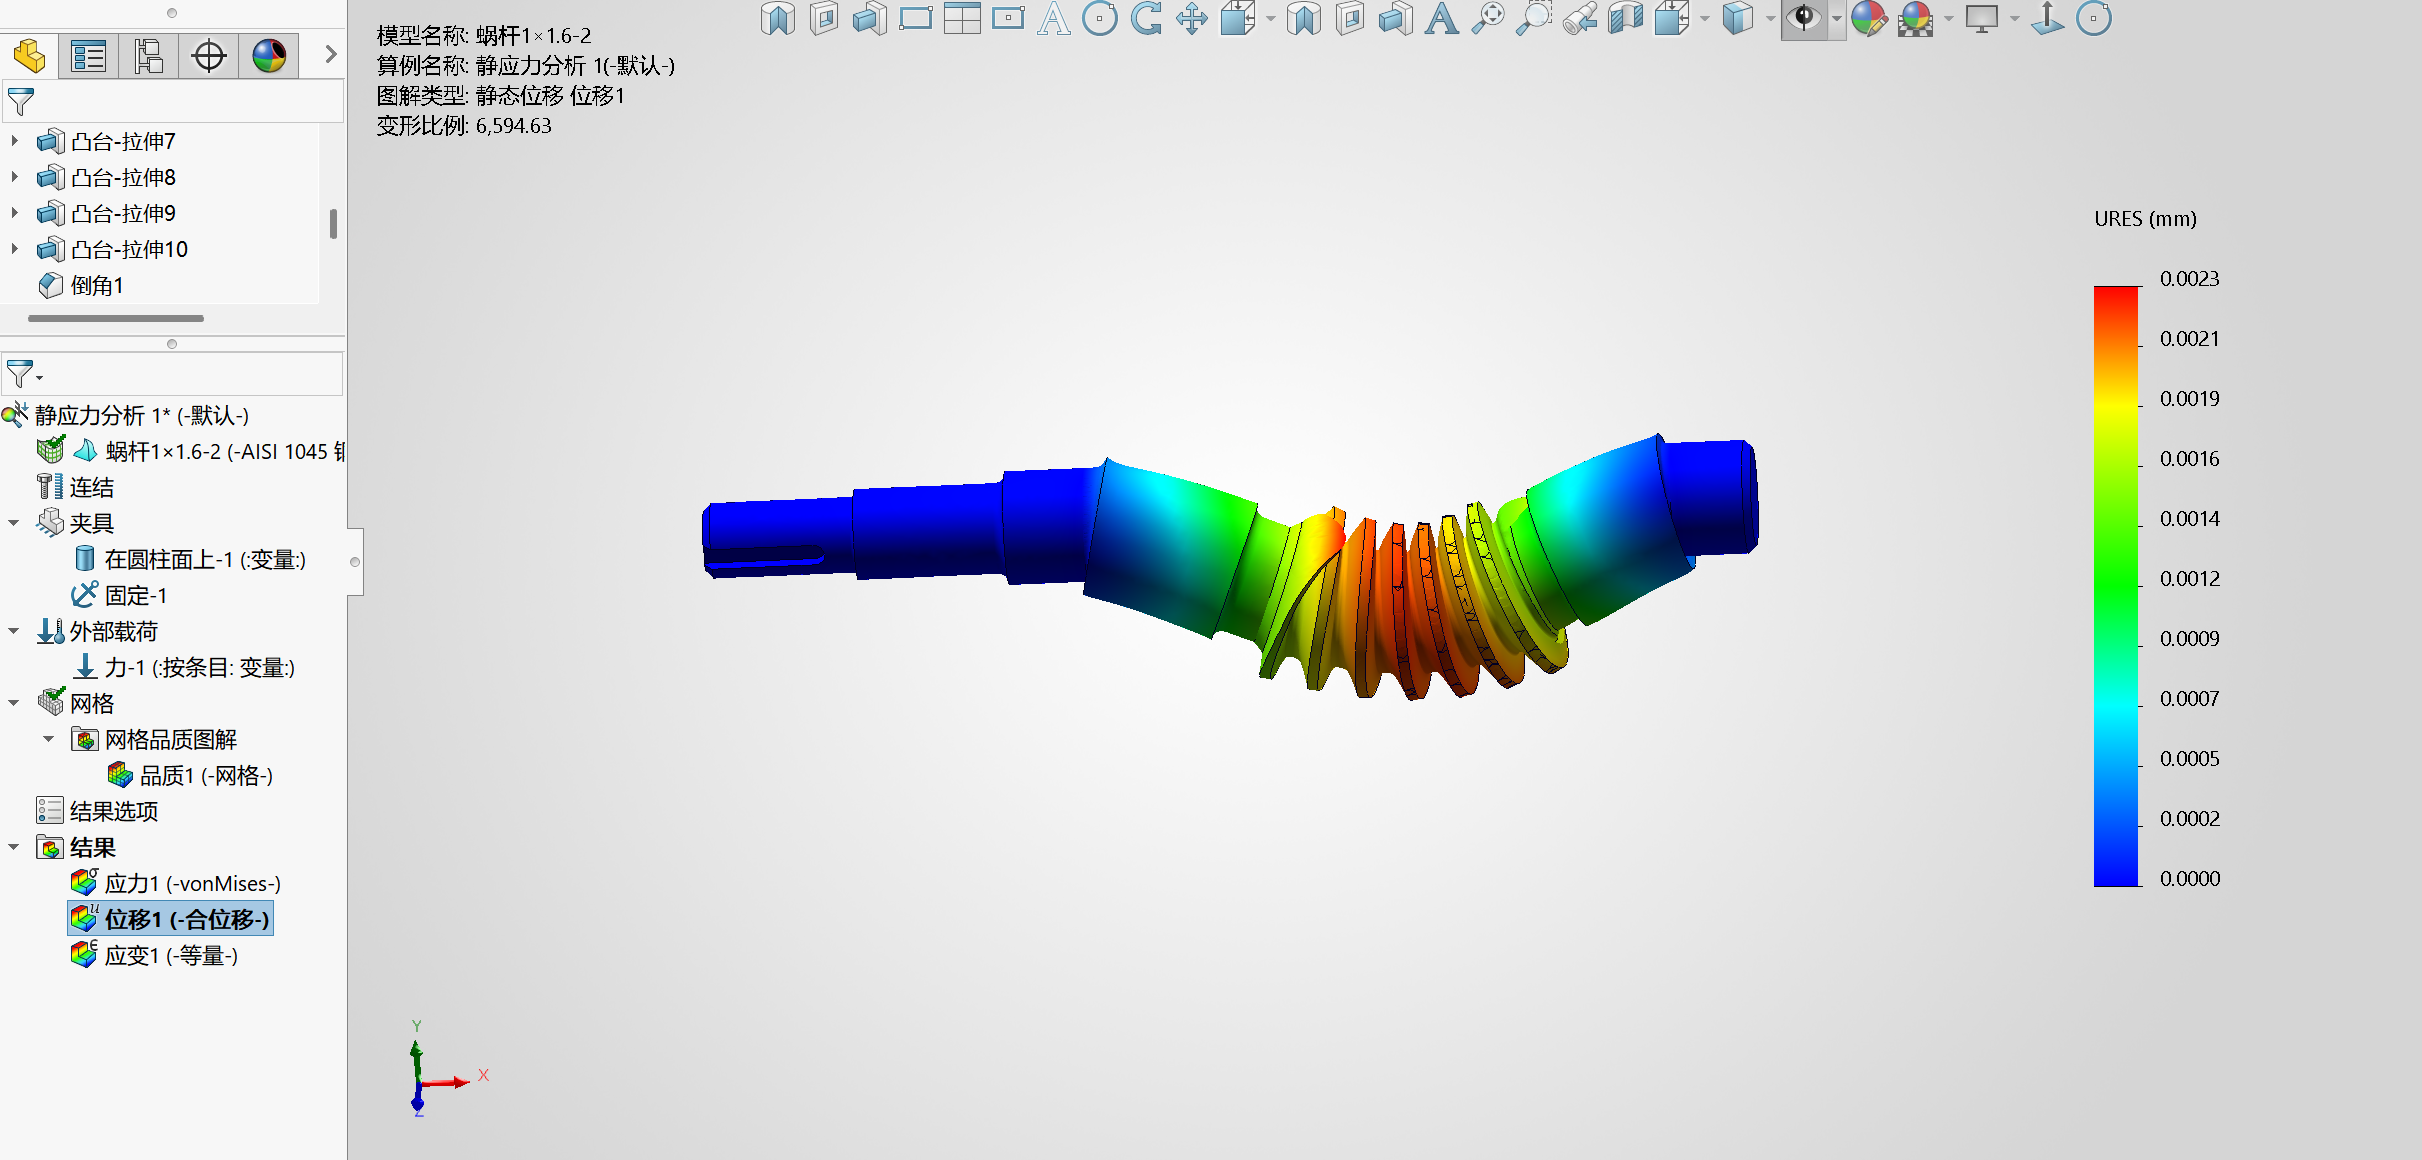
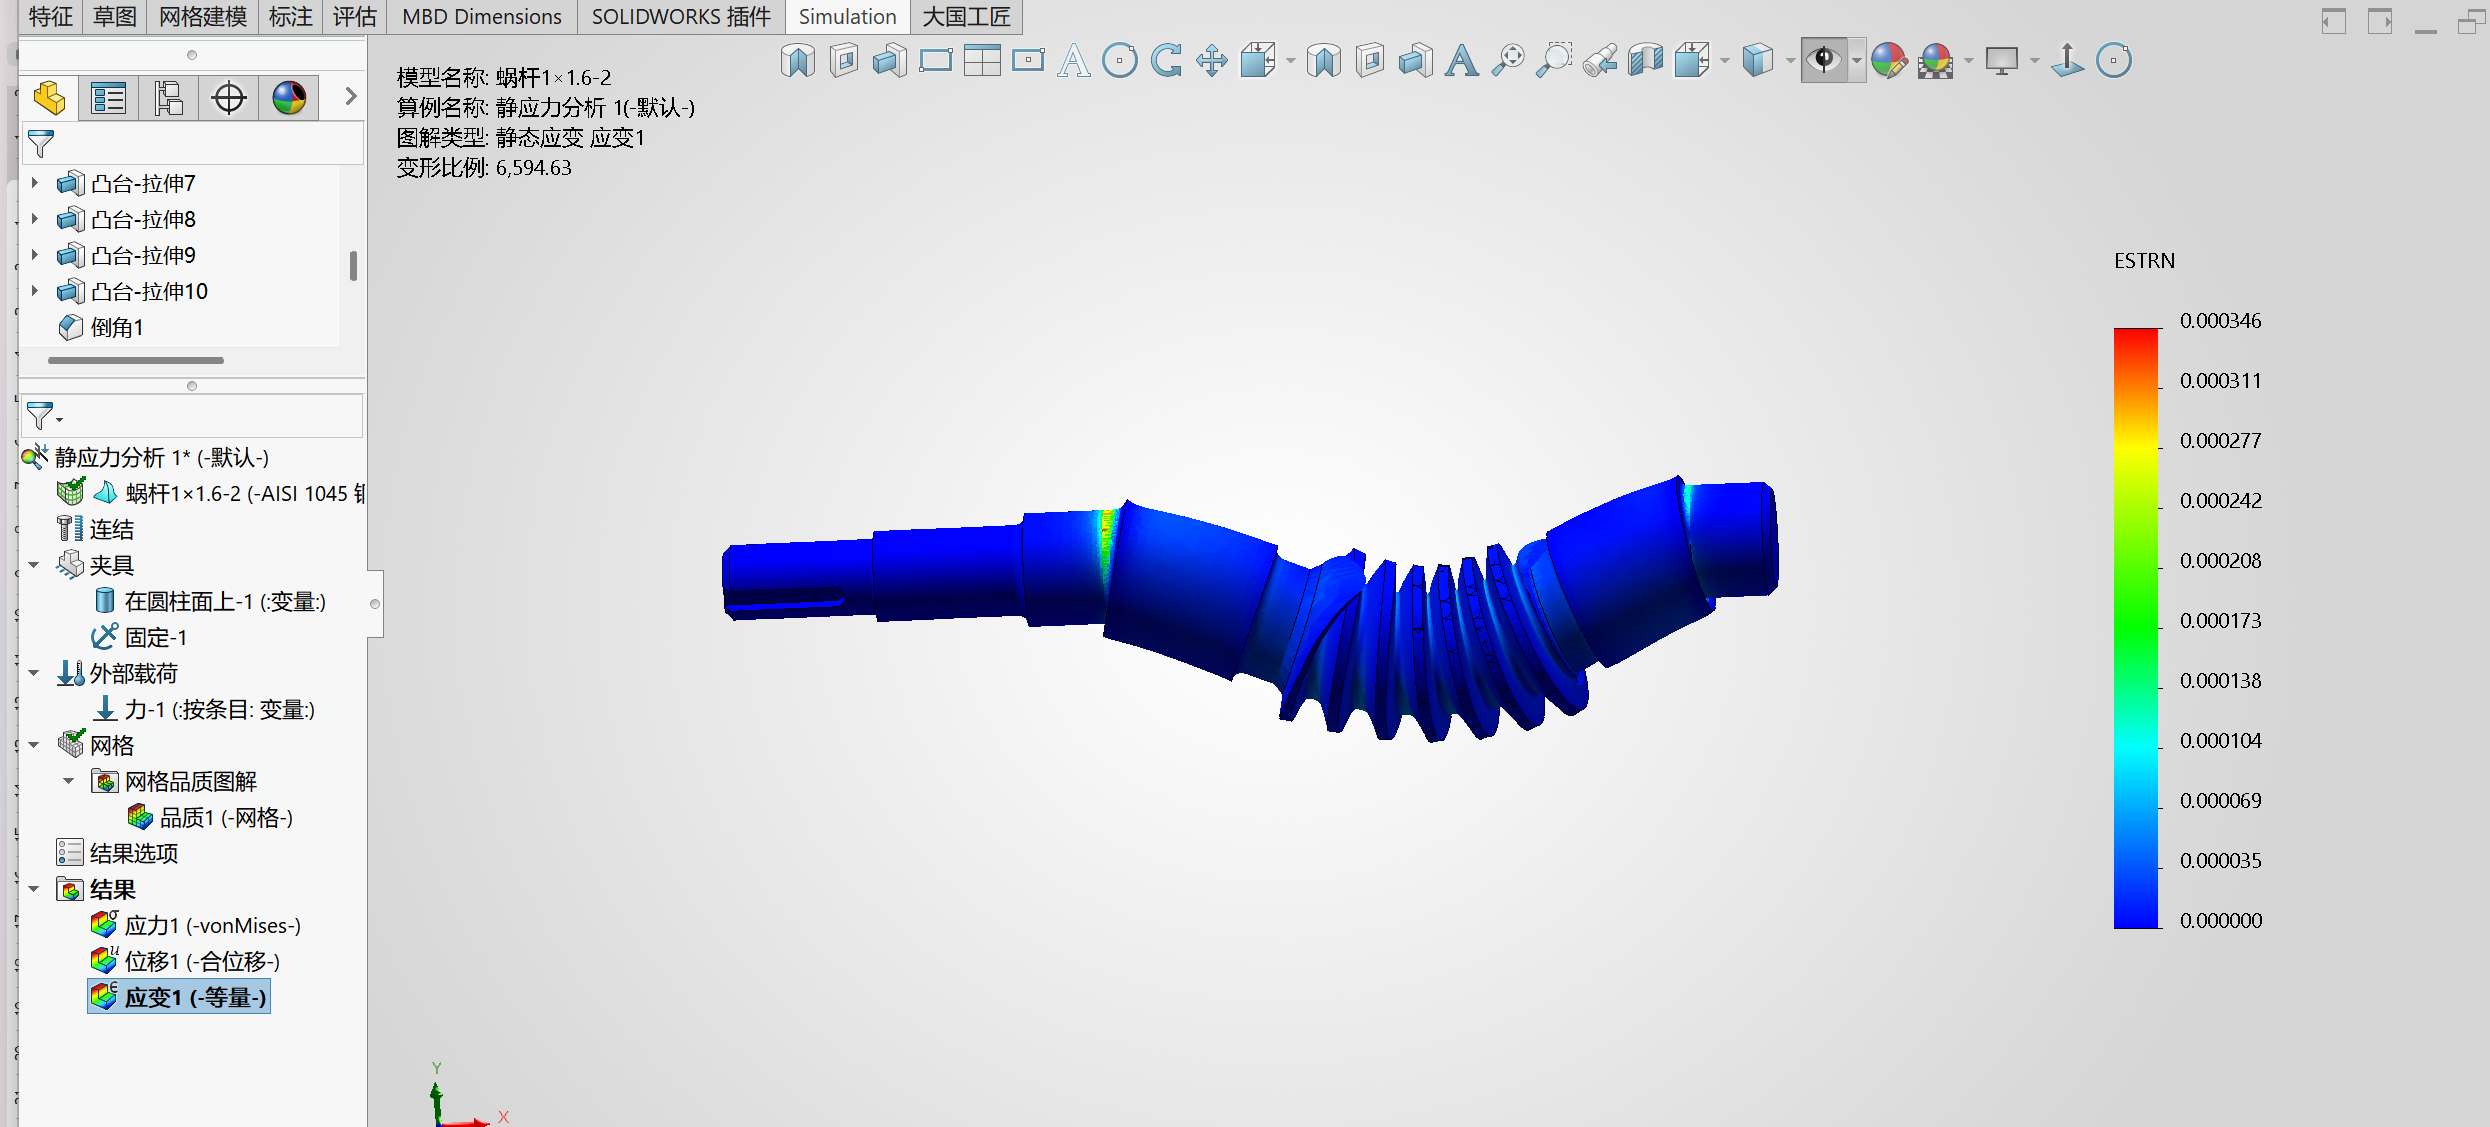
Engineered a high-torque worm drive transmission system for an automated agricultural sorting machine. Optimized the gear profile to reduce backlash by 15% and selected wear-resistant bronze alloys for longevity under continuous load.
  • SolidWorks
  • Gear Design
  • GD&T
  • Material Selection

Rapid Prototyping

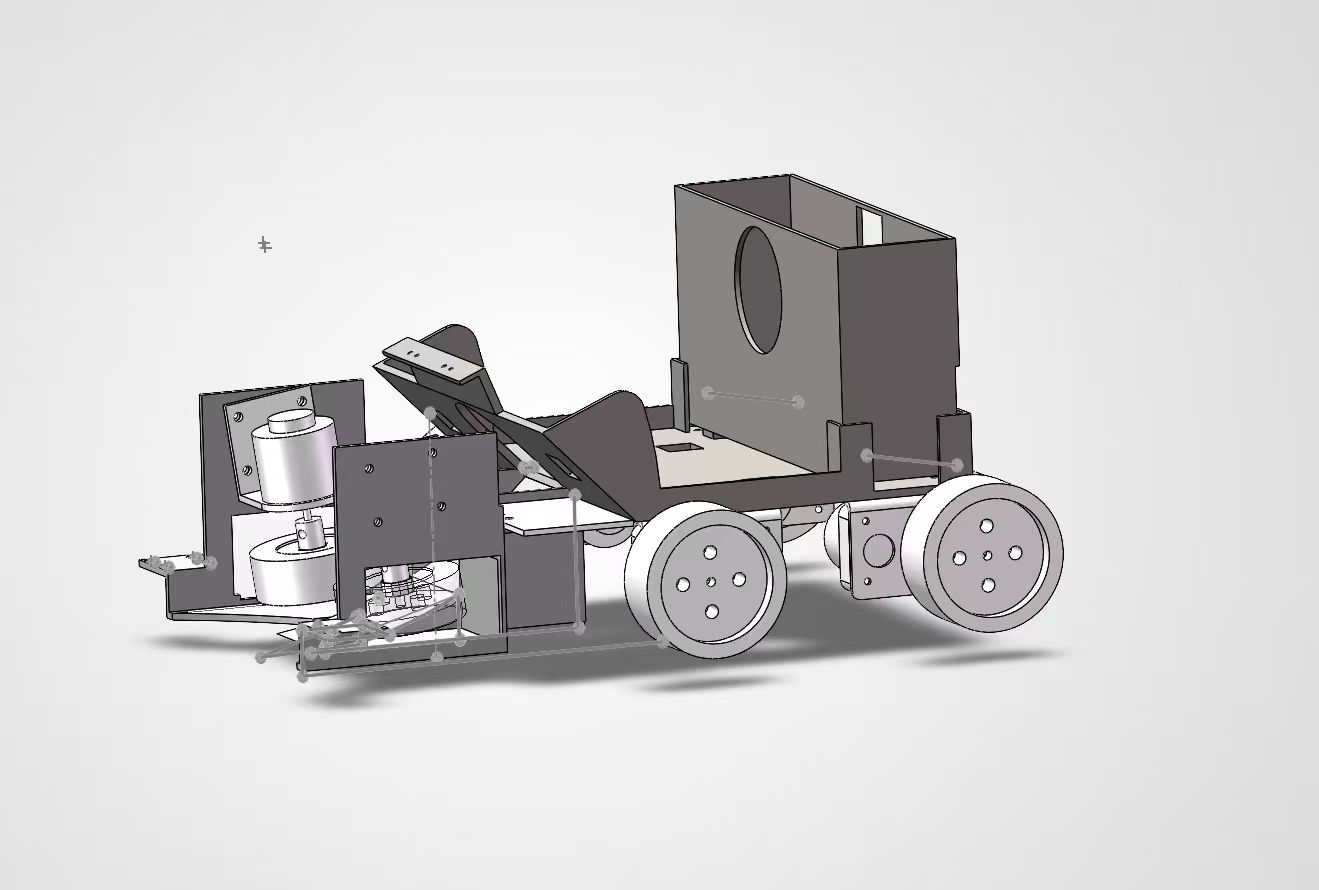
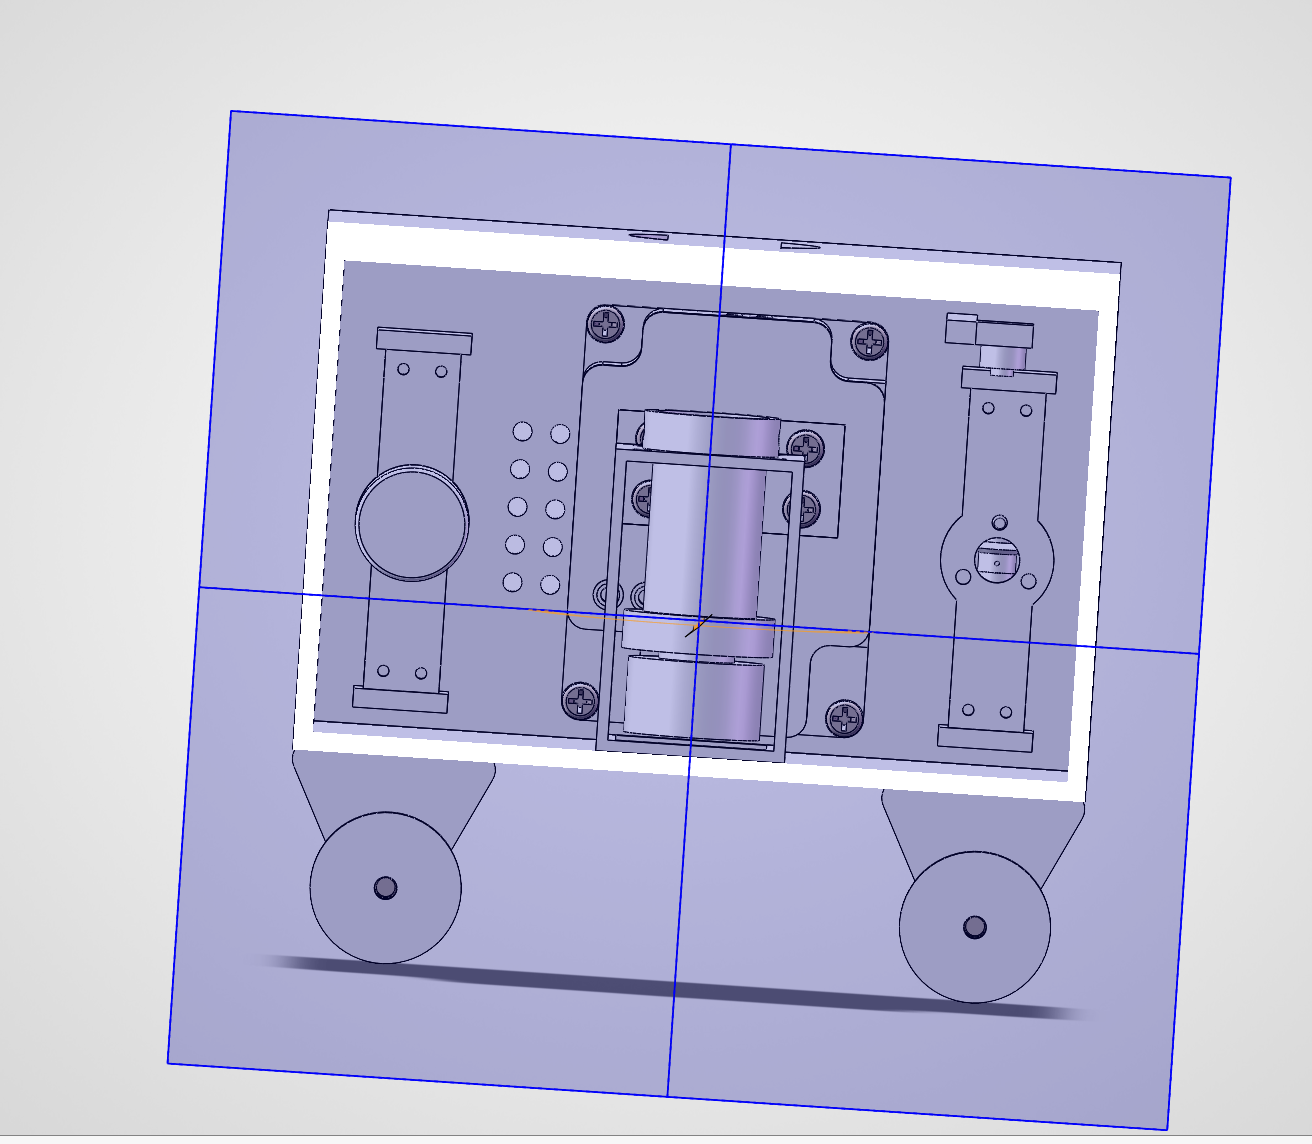
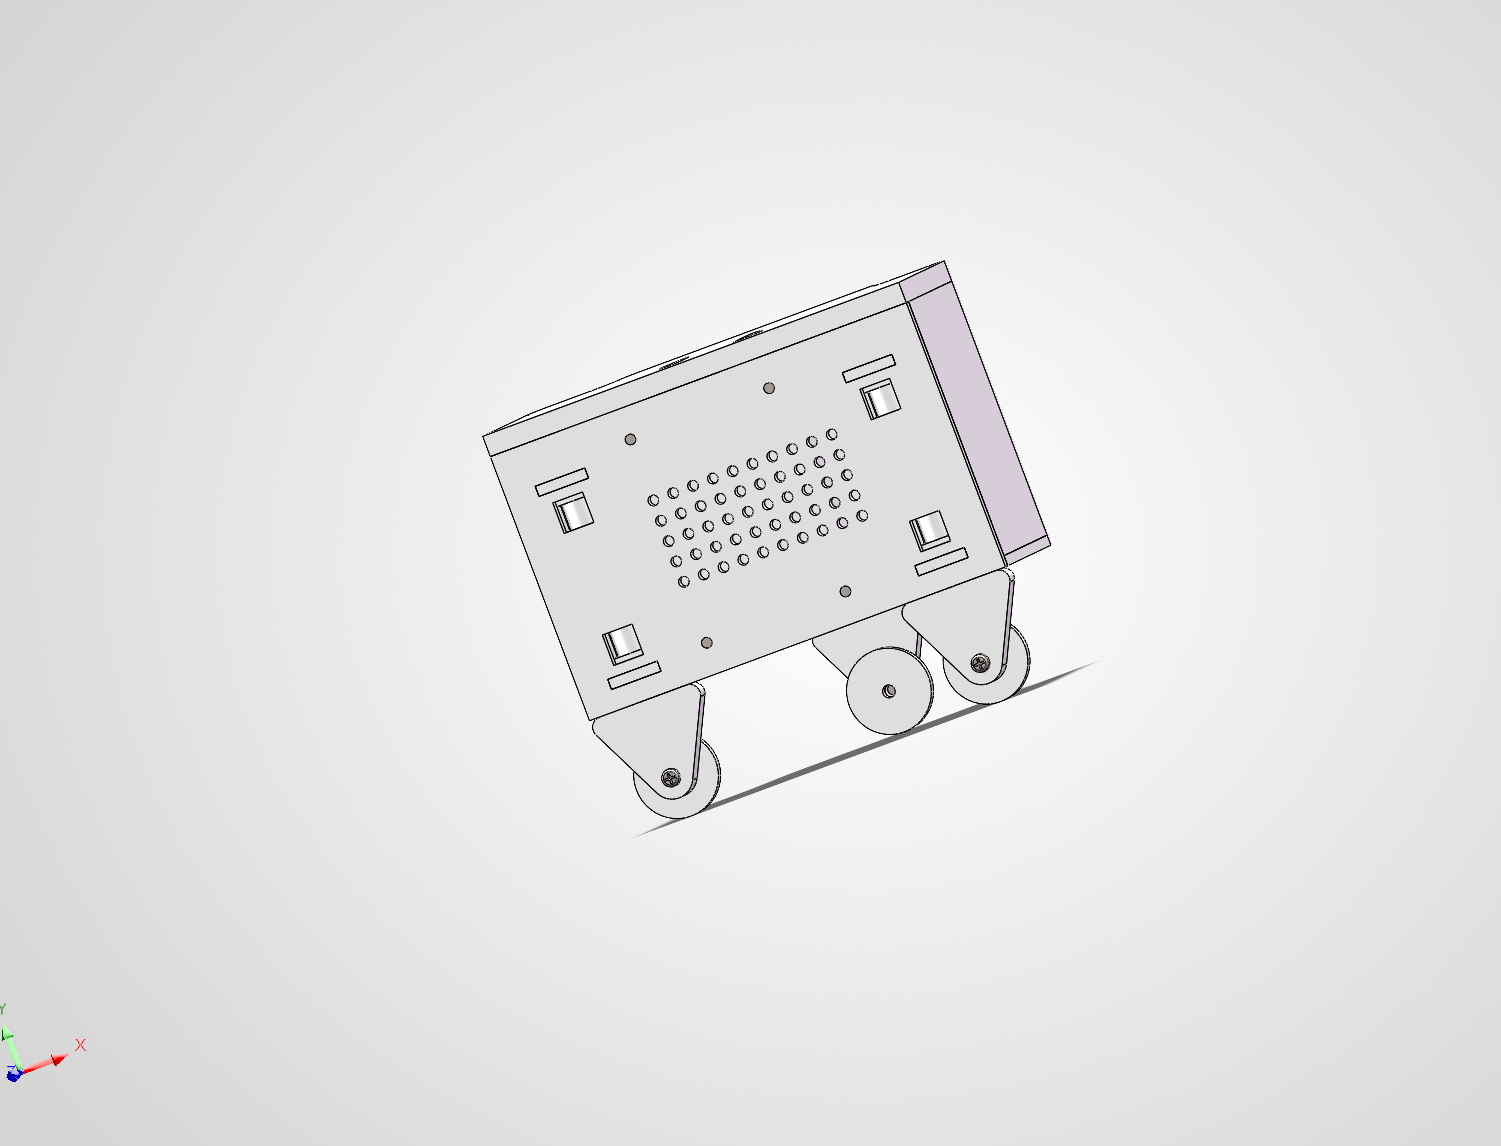
3D-Printed Ping-Pong Ball Collector

Designed and rapid-prototyped a lightweight, kinematics-driven cart to automatically collect ping-pong balls. Utilized FDM 3D printing for 80% of the structural components, optimizing print orientation for tensile strength and reducing overall weight by 2kg.

  • Kinematics
  • 3D Printing (FDM)
  • SolidWorks
  • Prototyping
Ping Pong Cart
Inspection Robot

Robotics & Simulation

Wind Power Inspection Robot

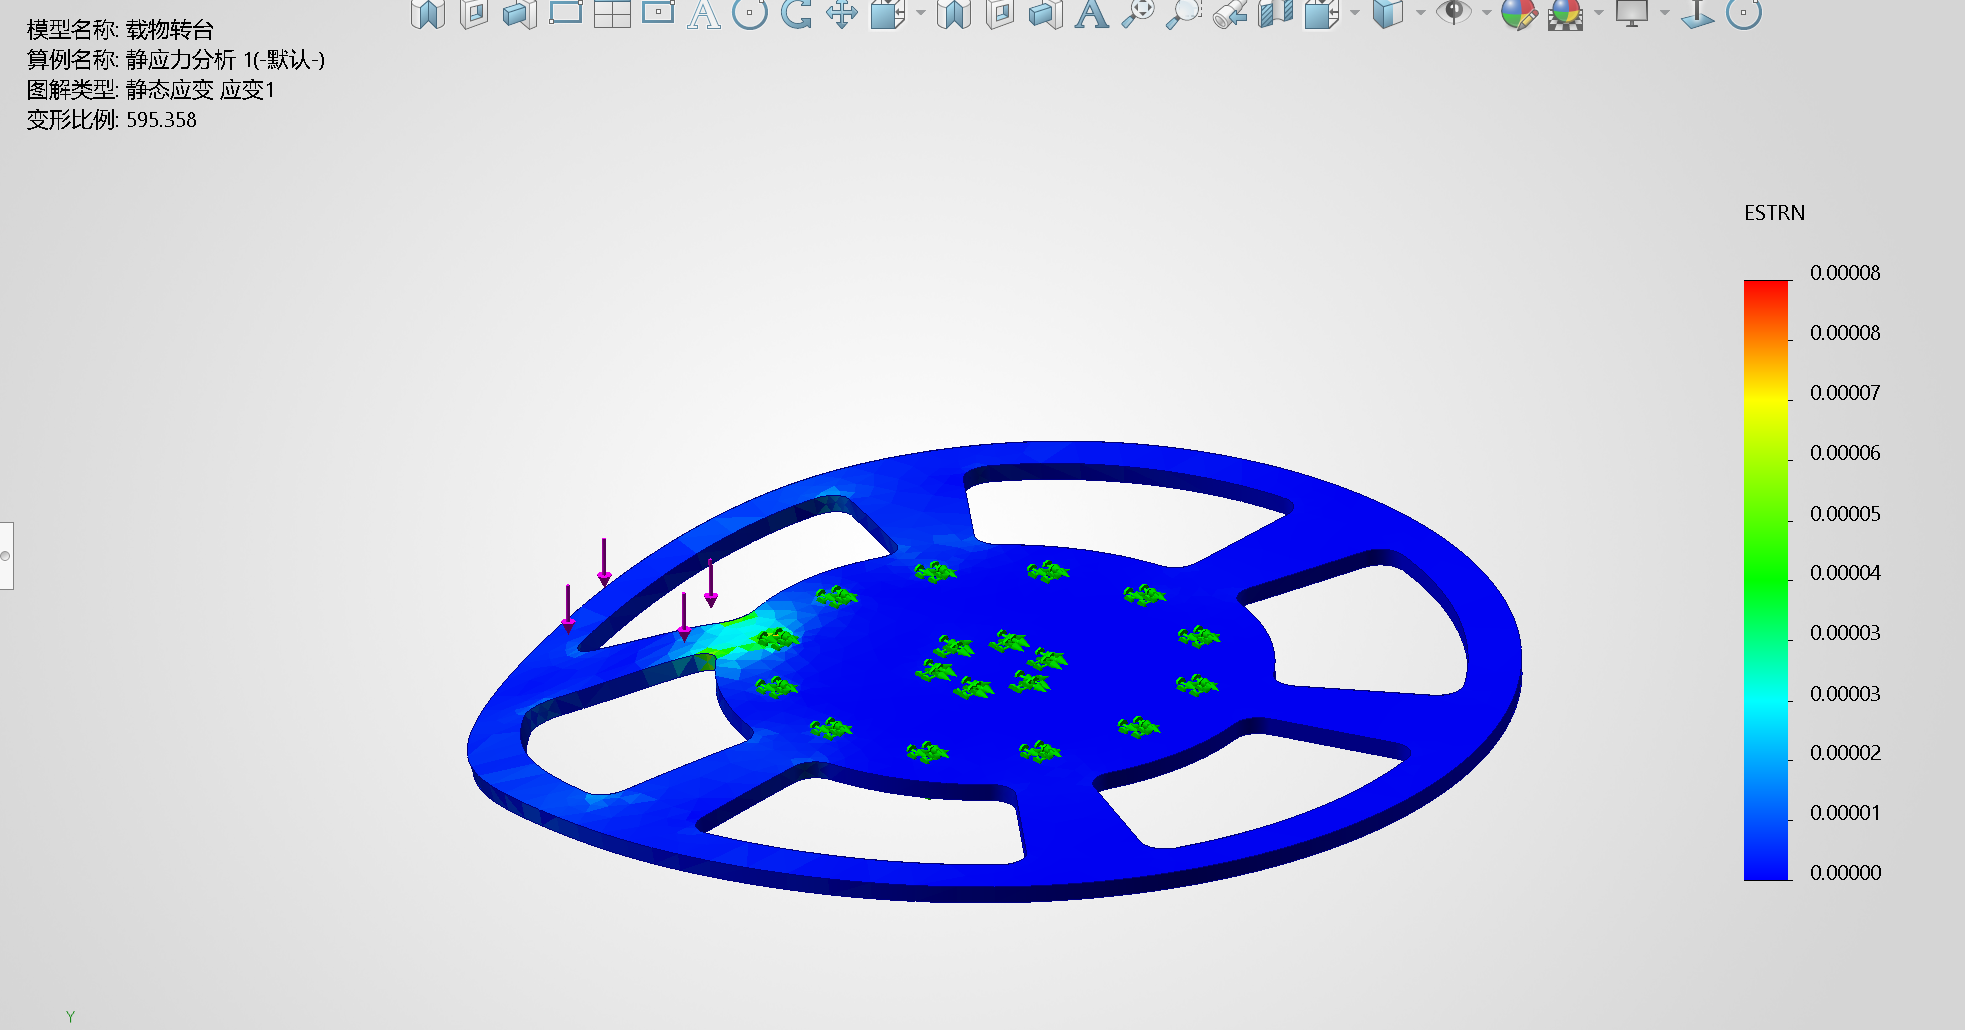
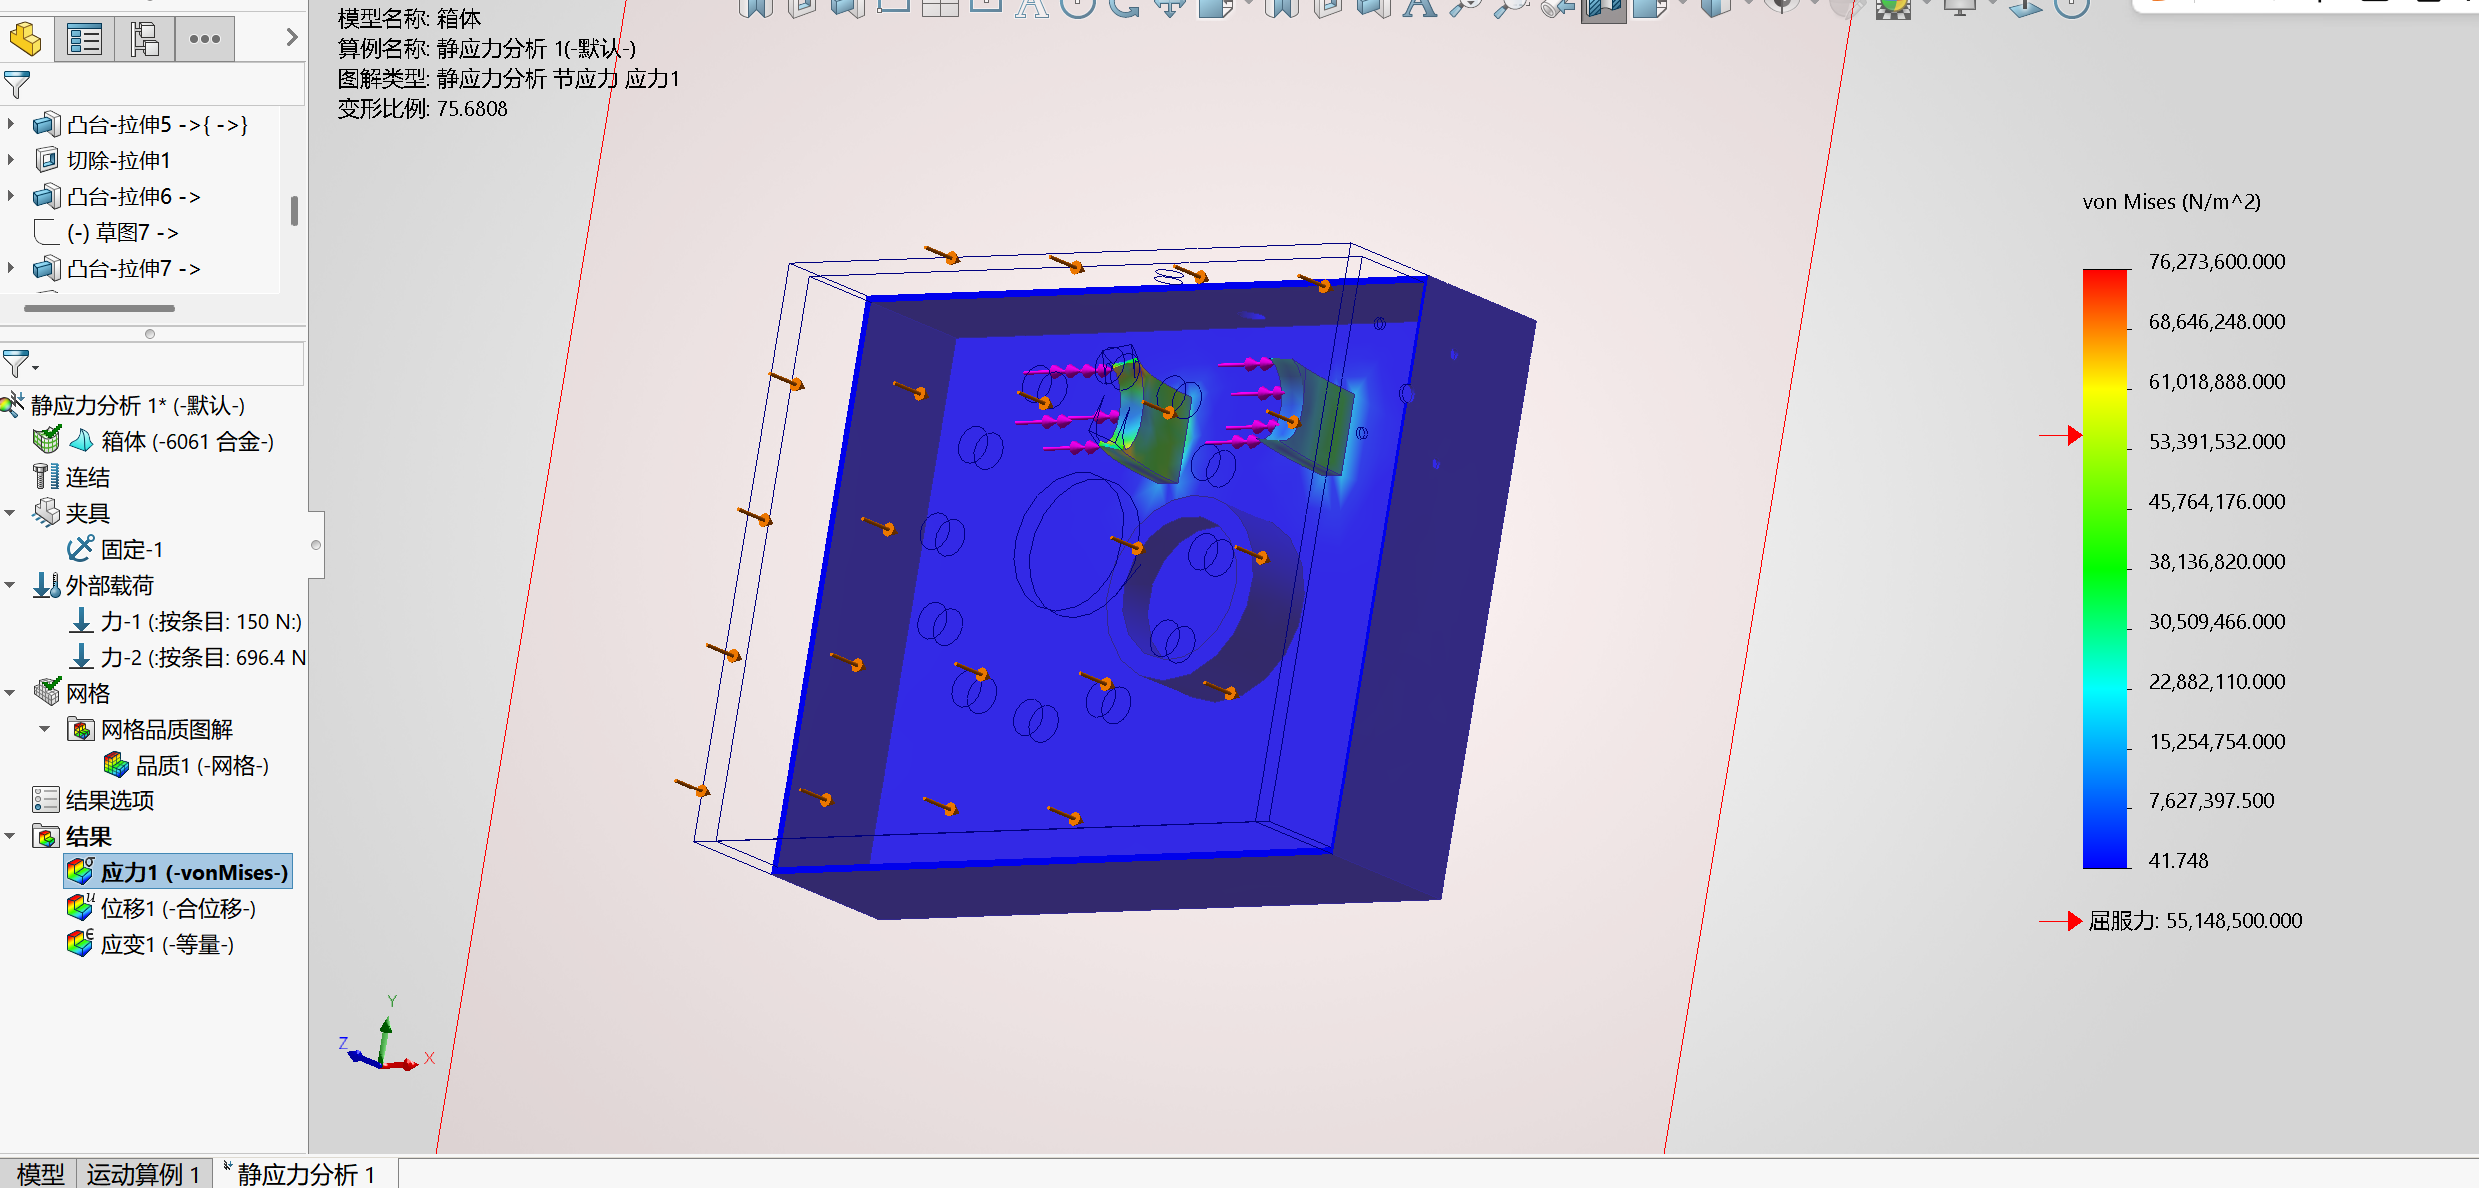
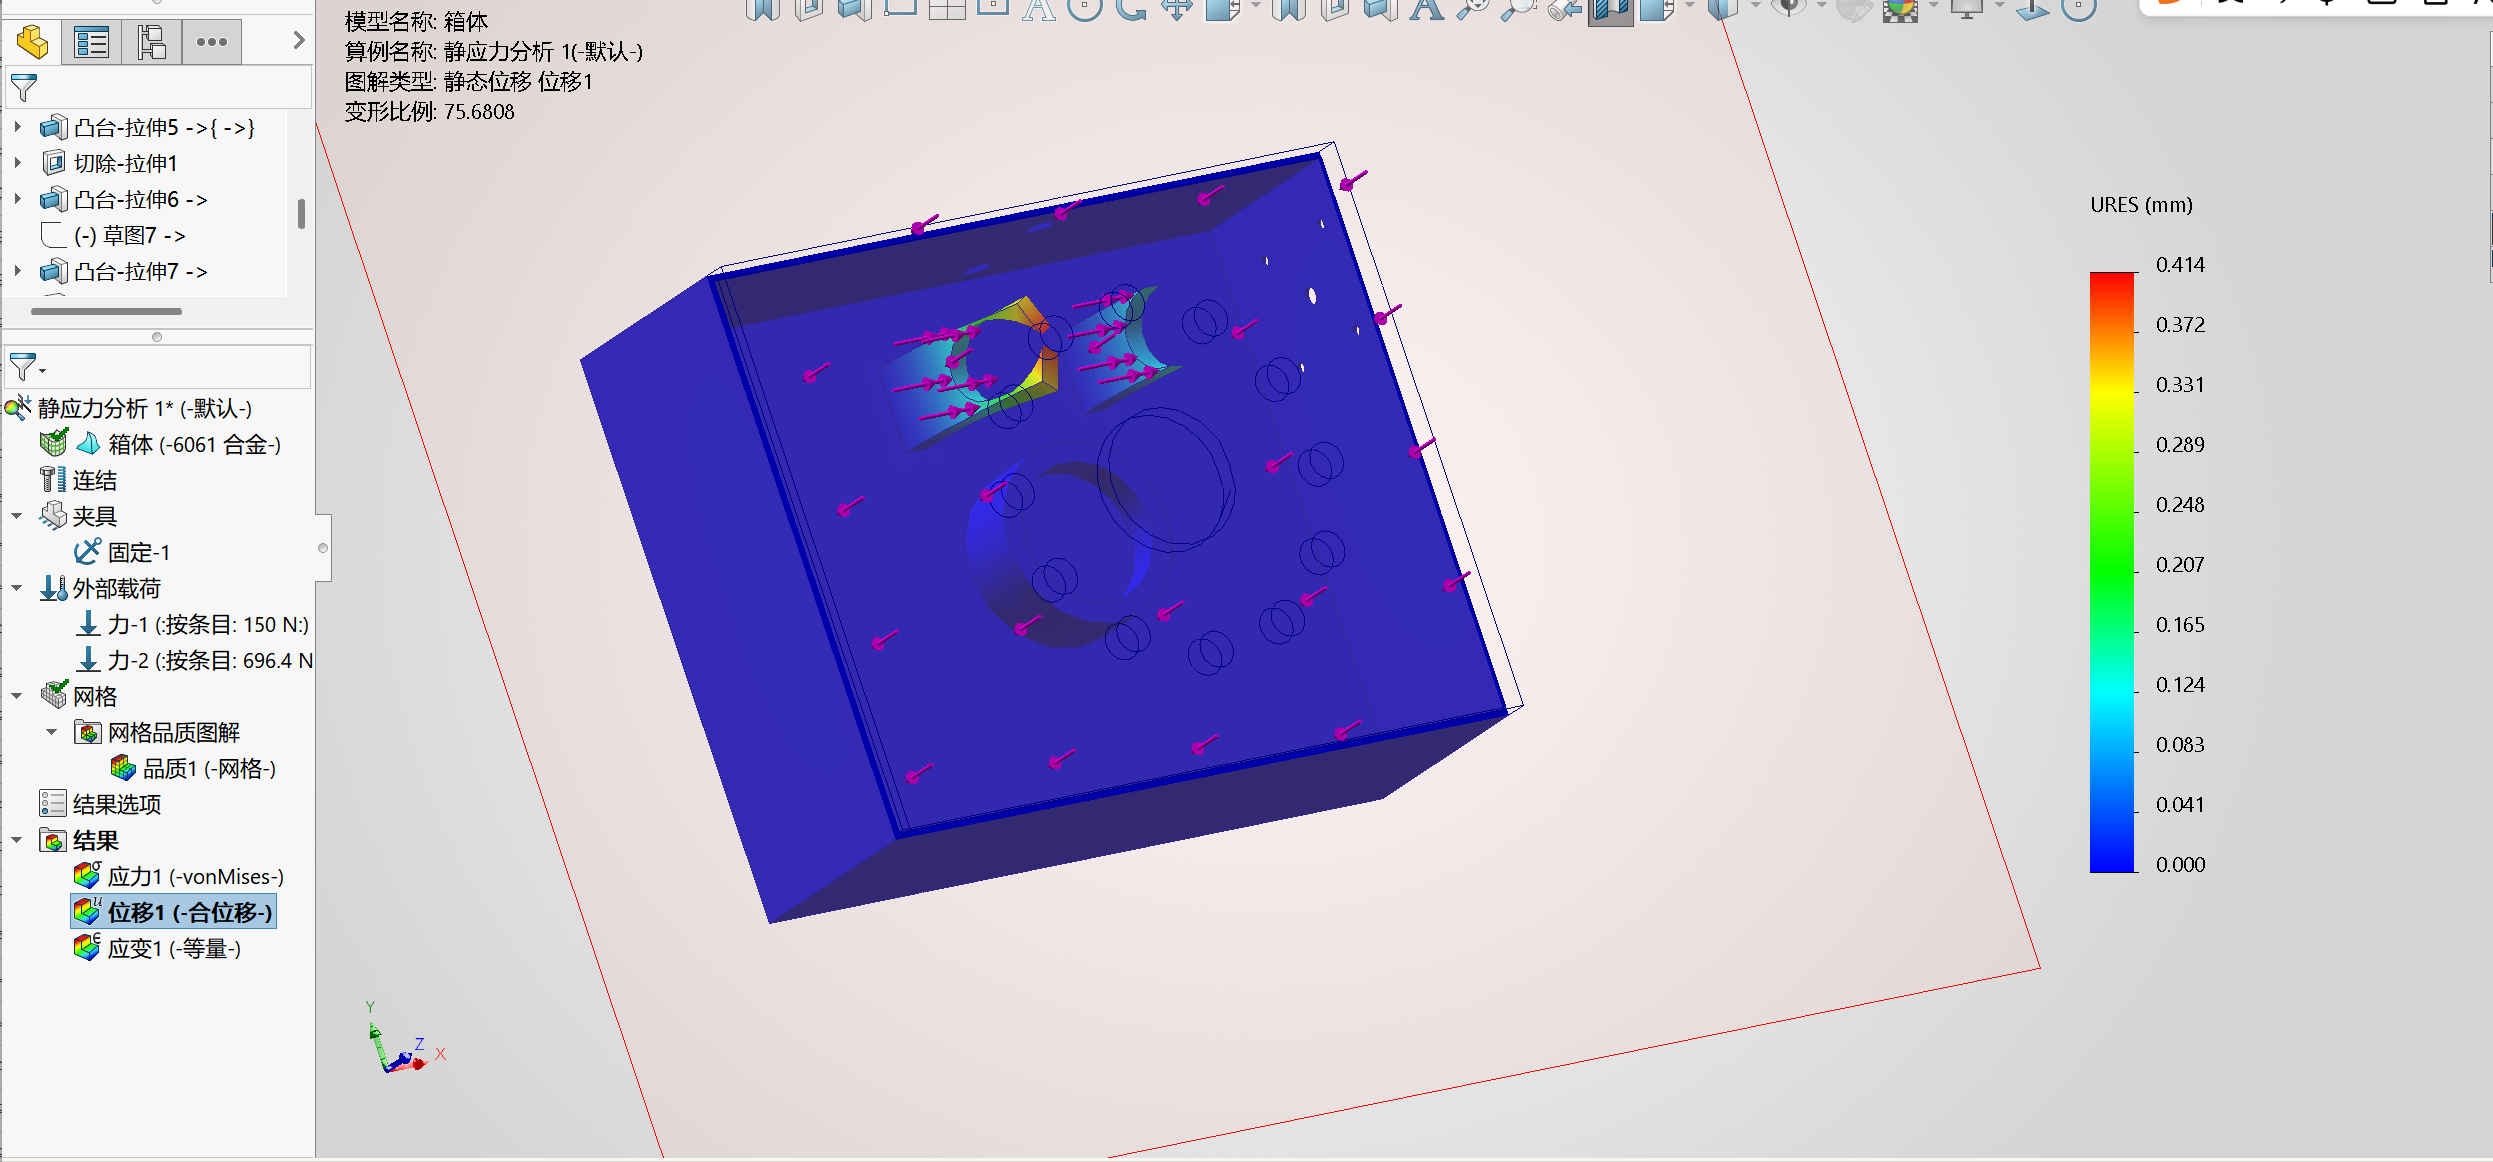
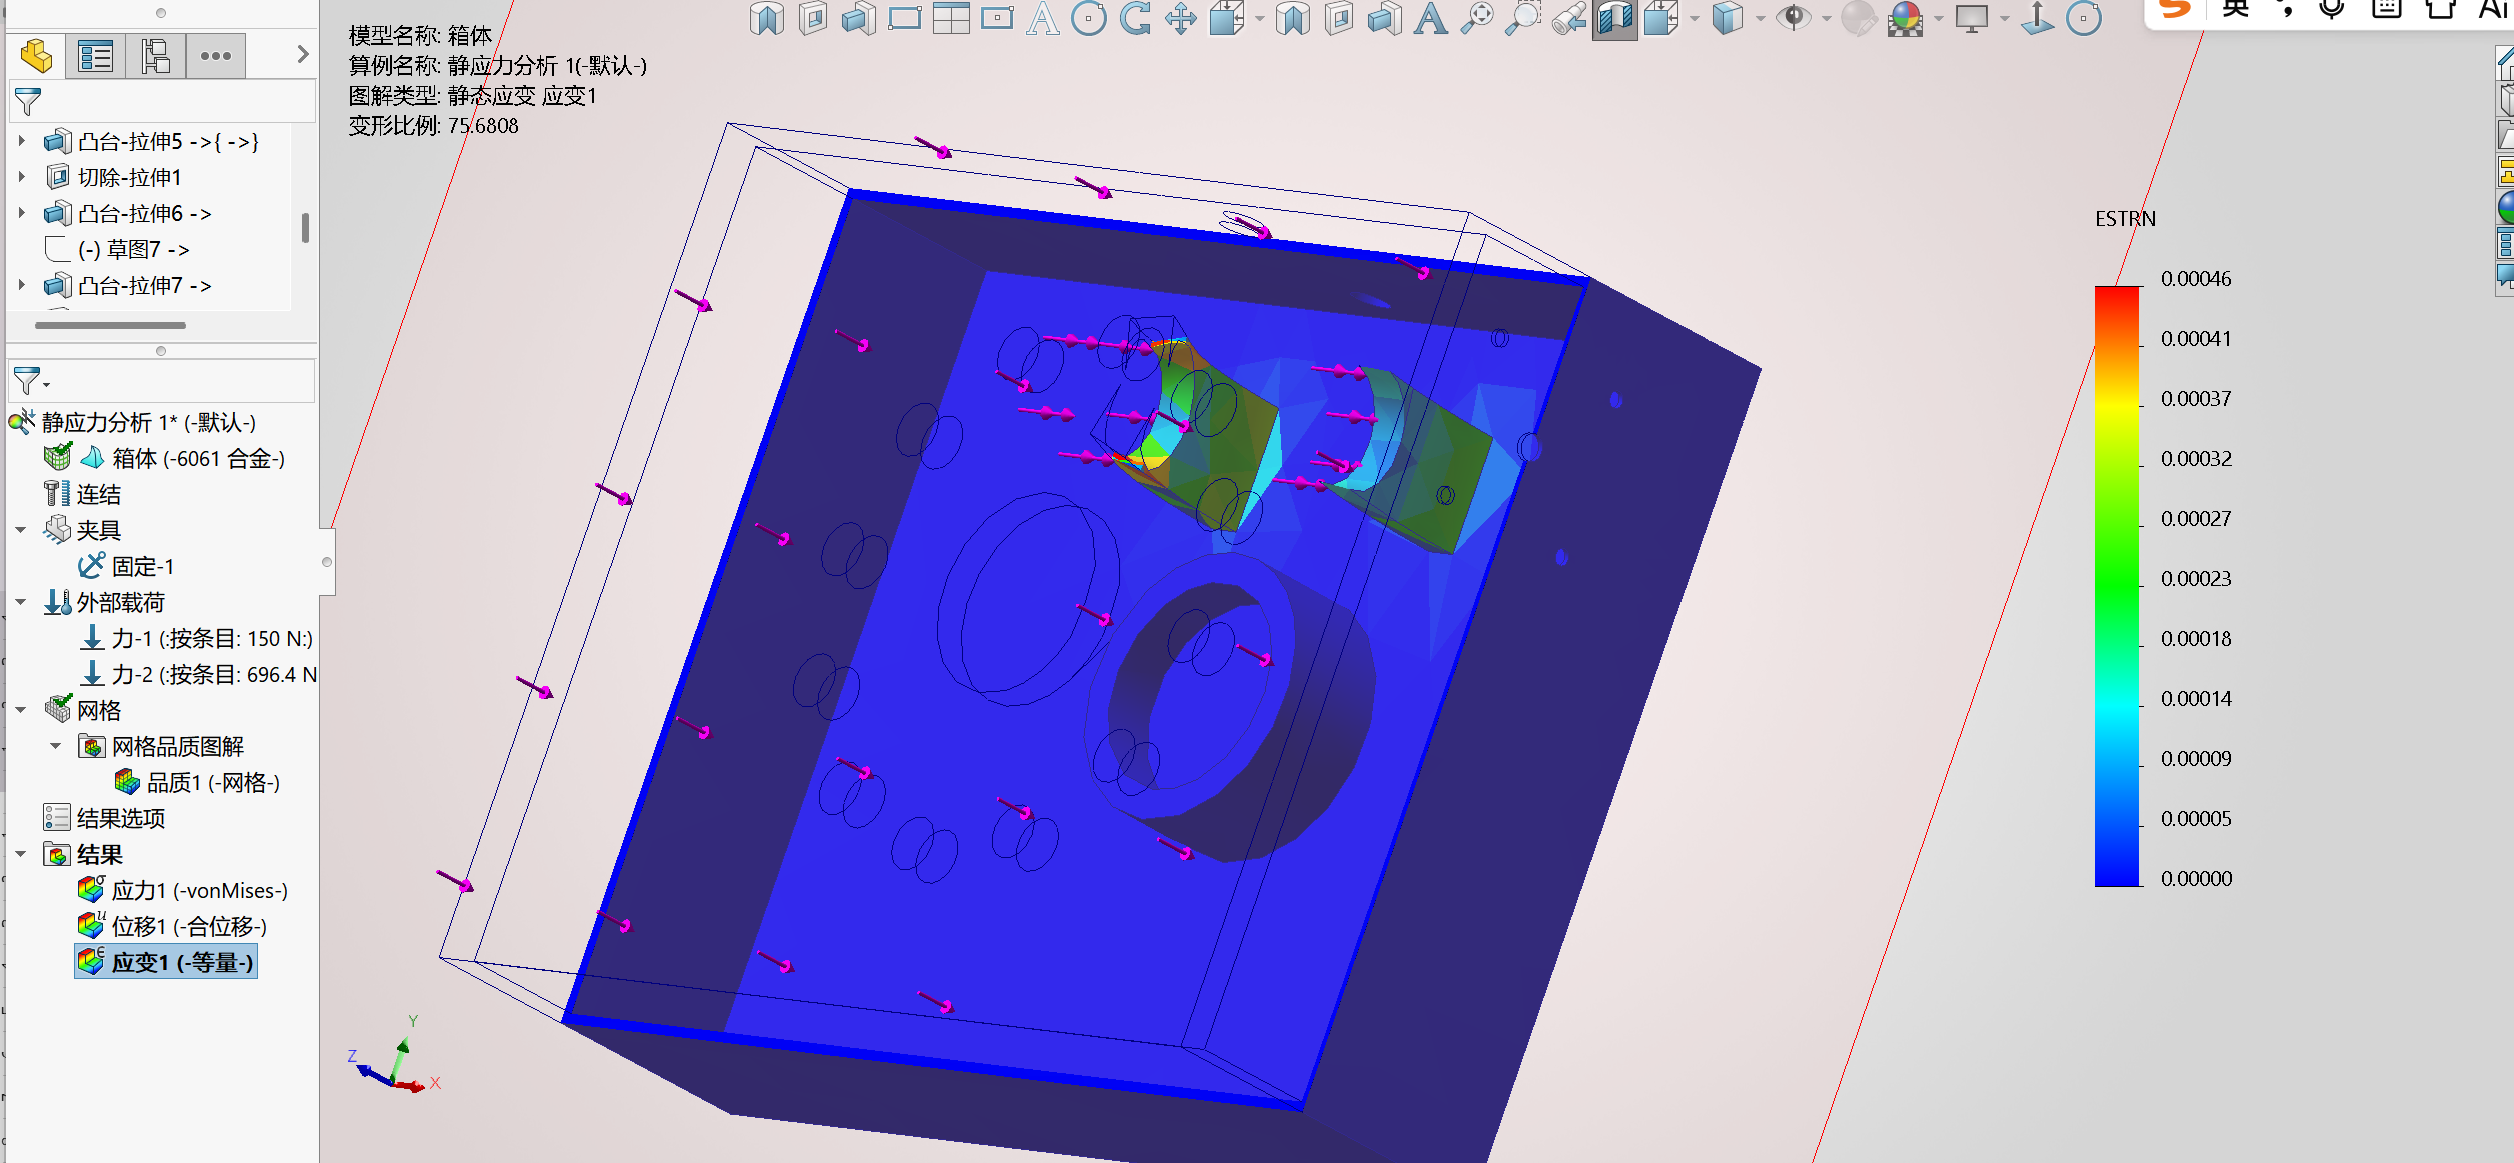
Developed the structural chassis and drive train for an autonomous inspection robot operating on wind turbine blades. Conducted extensive FEA simulations to ensure survival in high-wind, high-vibration environments while integrating Keil-programmed microcontrollers for motor control.

  • FEA Simulation
  • Keil (Microcontroller)
  • Chassis Design
  • Robotics

04. What's Next?

Get In Touch

Whether you have a question about a project, need a structural design consultation, or just want to say hi, my inbox is always open. I'll try my best to get back to you!